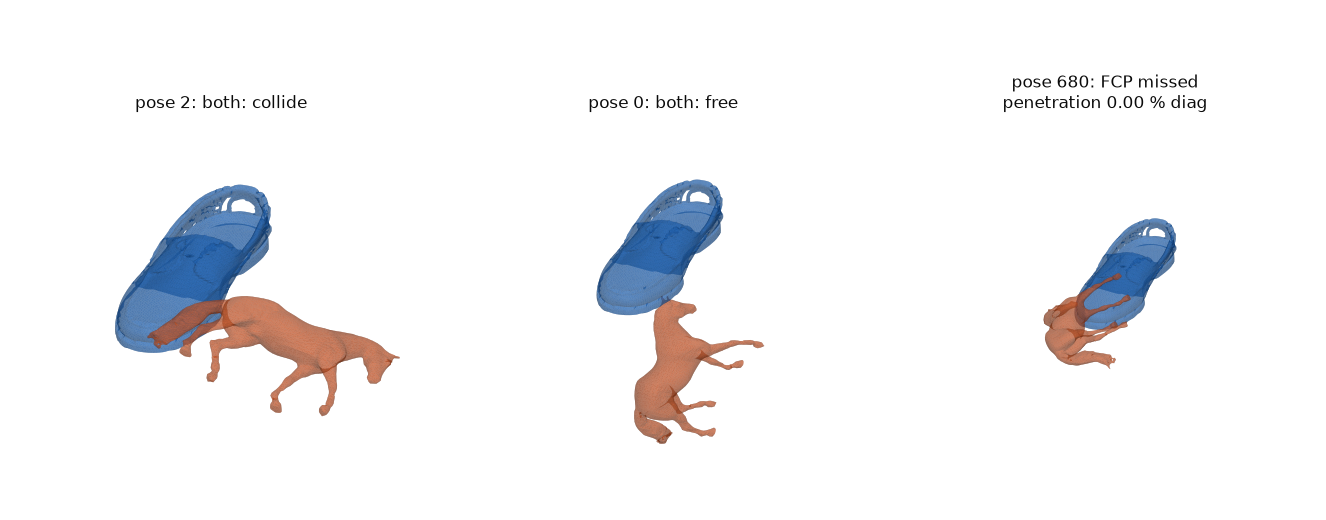
fcp_2910_collision, v2 · package v5.4 (parts="tracked-fit", branch caps-cutfix) · GTX 1650 (4 GB), 12 CPU threads · 1024 layers, N 128, M 64, 2048 samples per ring, min island area 0, cut at 1e-08 energy left or 5 MB · query: 512 ring vertices, rule nearest · generated 2026-10-30 04:32 · v1 (1024 layers, N 64, 12288 atoms; with the dog and elephant)
| query | set | FCP | best mesh method | FCP speed-up | error bound (% diag) | correct | size |
|---|---|---|---|---|---|---|---|
| Inside-outside, GPU | 11 objects, 1024 layers | 9.6 ns/pt | Embree 50.1 ns/pt | 5.2× | 0.32 % | ≤ 2.2 MB | |
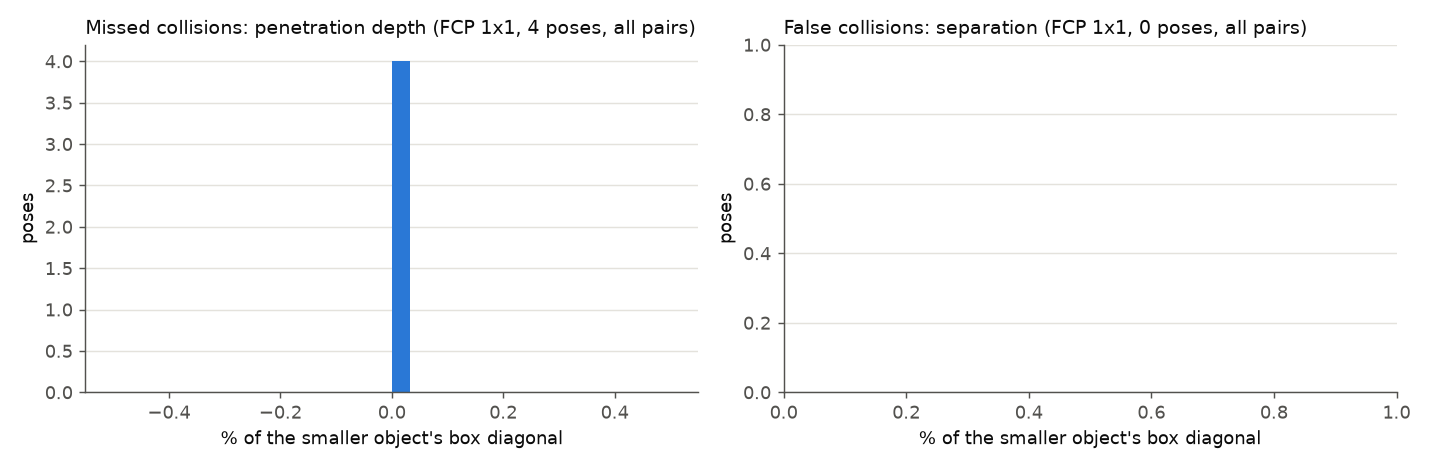
| Collision, GPU | 11 pairs, 1024 layers | 7.0 µs/pose | FCL 18.2 µs/pose | 2.6× | miss 0.44 % (0.03 % w/o gear), false 0.00 % | 99.93 % | |
| Collision, GPU, every other sample | 3.2 µs/pose | FCL 18.2 µs/pose | 5.7× | 99.84 % | |||
| Inside-outside, CPU (v5.5) | 12 objects (household, figurines, spring, knot), 256 layers | 24.6 ns/pt (12 thr) | Embree 52.4 ns/pt | 2.1× | 0.34 % | ≤ 1.0 MB | |
| Collision, CPU (v5.5) | 11 pairs, 256 layers | 24.0 µs/pose (12 thr) | FCL 18.4 µs/pose (1 thr) | 0.8× | miss 0.00 %, false 0.05 % | 99.94 % | |
| Collision, CPU, every other sample | 6.3 µs/pose (12 thr) | FCL 18.4 µs/pose (1 thr) | 2.9× | miss 0.36 % | 99.92 % |

CPU, 12 objects: household, two figurines, the spring and the knot (v5.5): error bound (left axis) and time (right axis, log) against the layers; (a) points against Embree, (b) collision against FCL. The GPU results are in sections 2–4.
parts="tracked-fit" (with decision 29's cut fix); the study patches three encoder constants
in-process and replaces the selection's padded array (lowmem.py); nothing in the package is changed.scripts/fcpq.py). The rings at the layer centres are evaluated once
from the stored polynomials (512 vertices each; the ring tables take 0.1–0.3 s per object). A point is inside when the
signed count of the parts whose ring at the nearest layer centre contains it is positive (hole parts count −1):
one even-odd crossing test per part present at that height, on the edges of the point's y-bin only. The height is read
to half a layer (0.05 % of the diagonal or less). Collision: the ring vertices of each object (strided) are mapped into
the other's canonical frame and tested; a pose collides when any is inside. All poses in one CUDA launch (or a numba
prange). CPU and GPU give the same answers.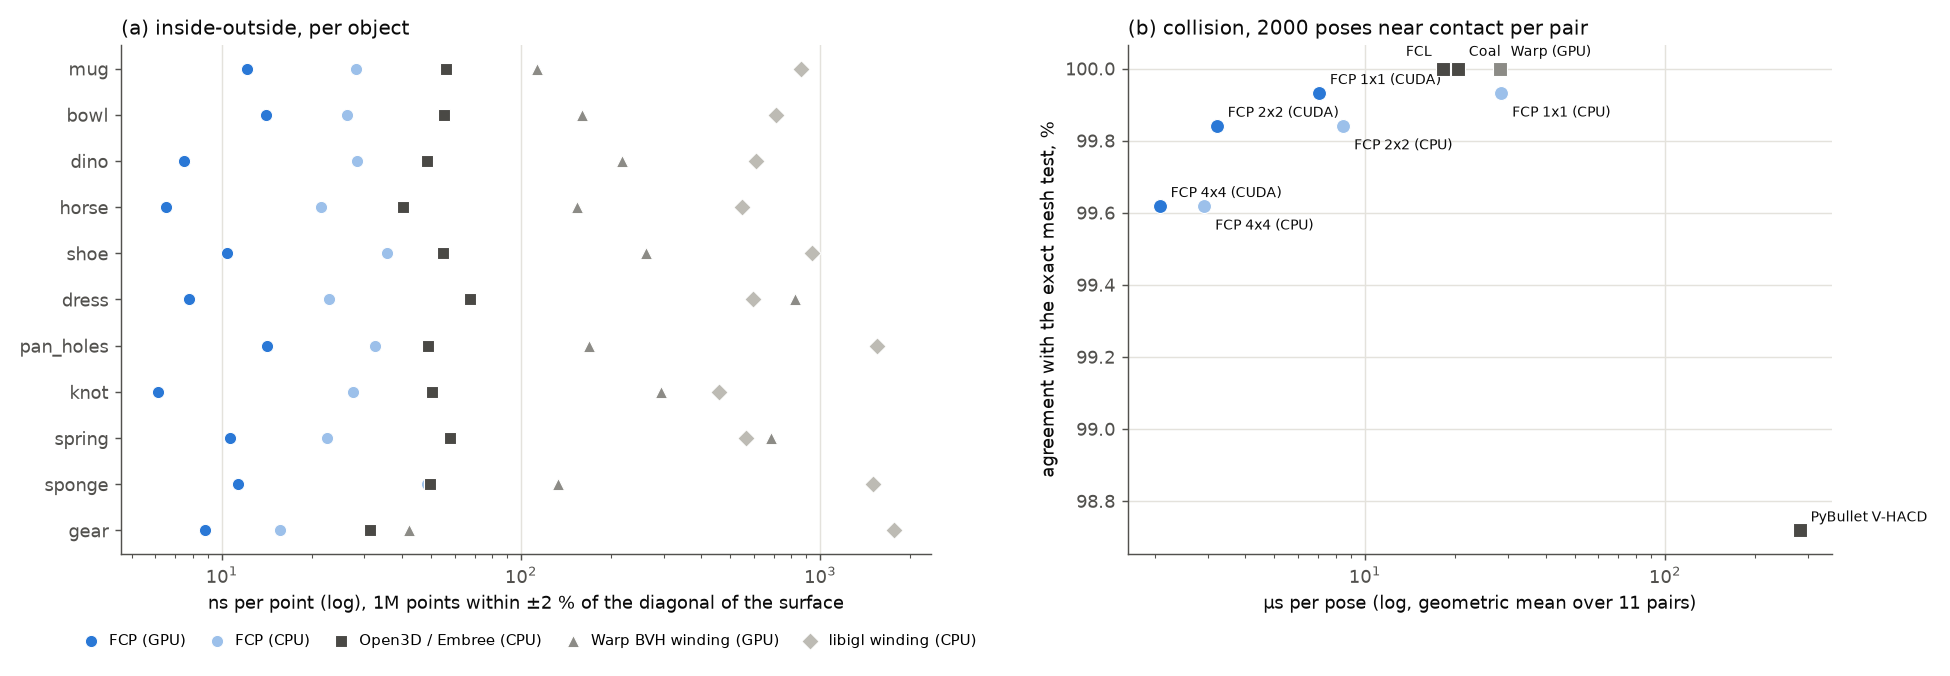
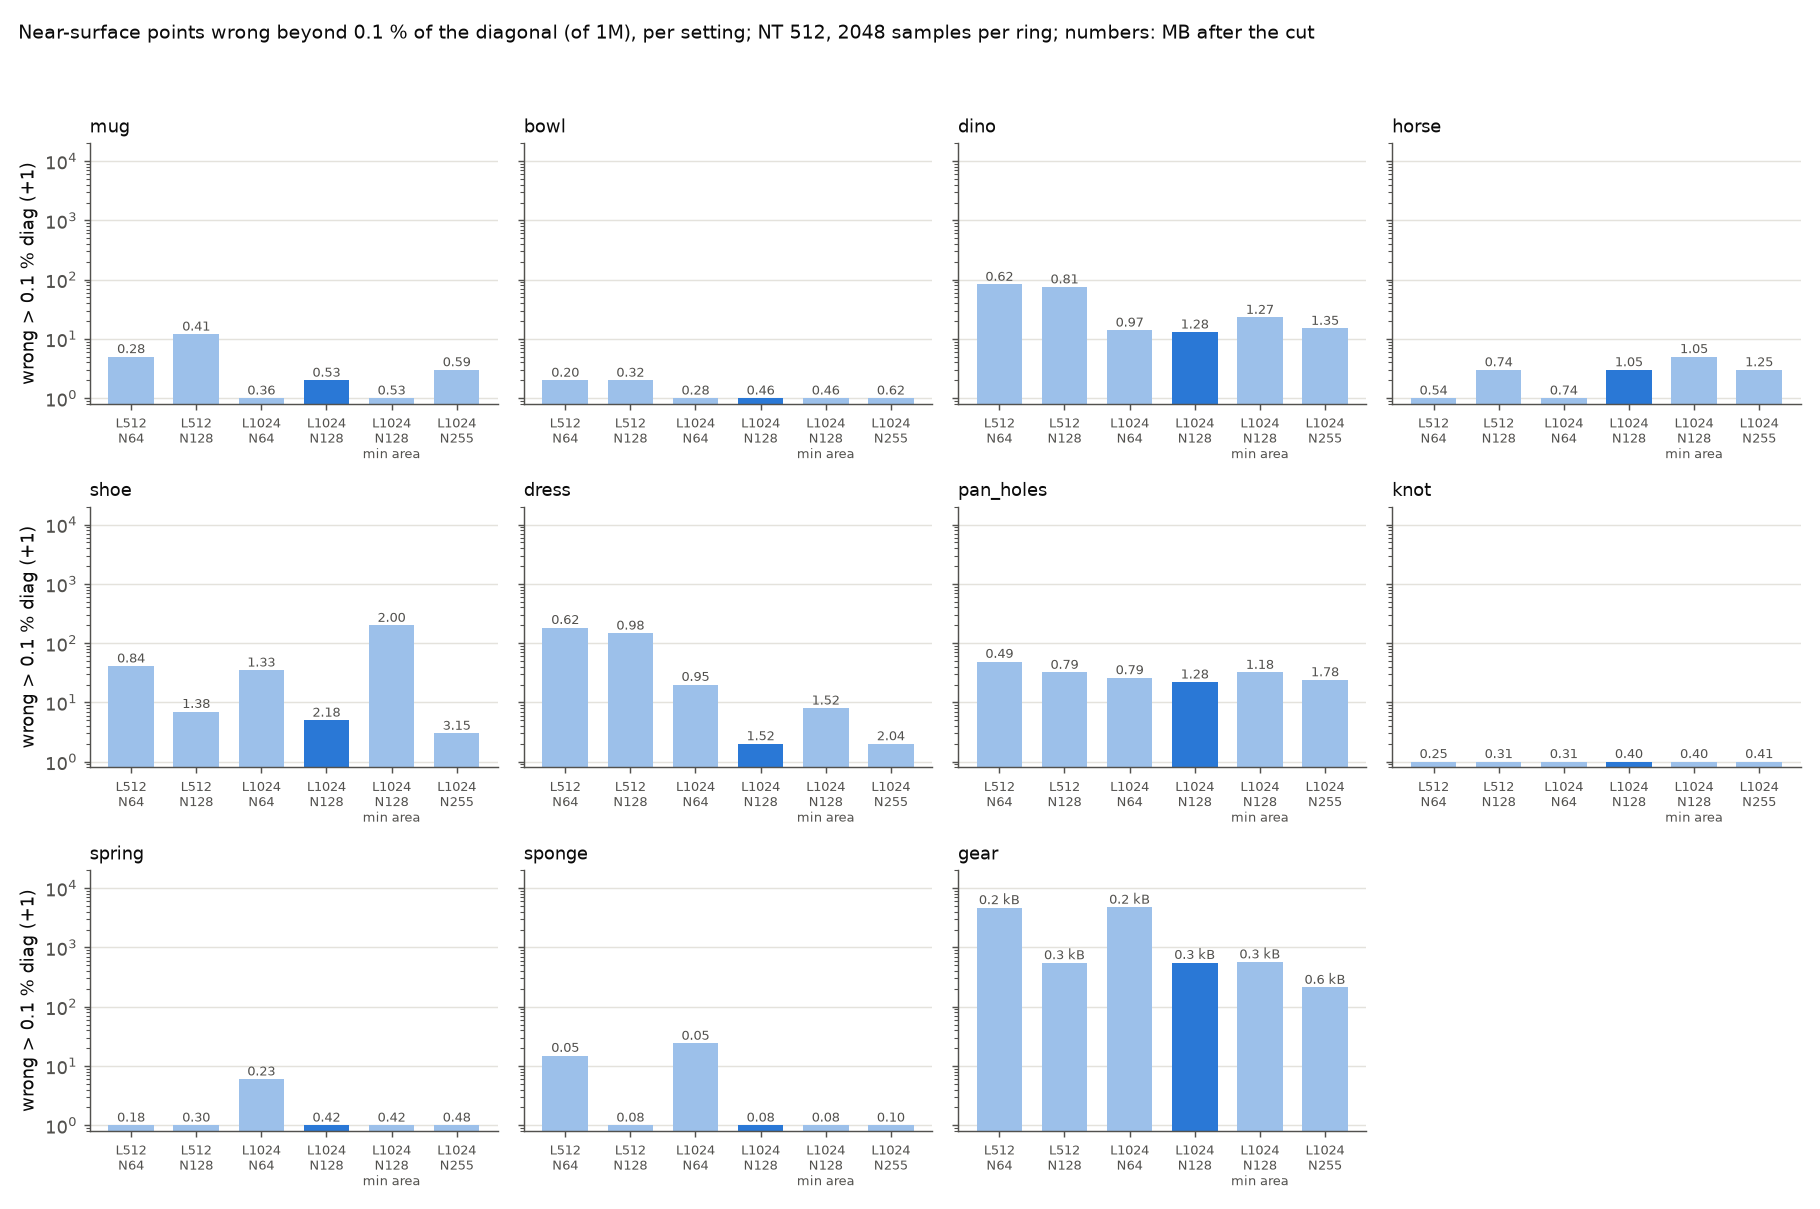
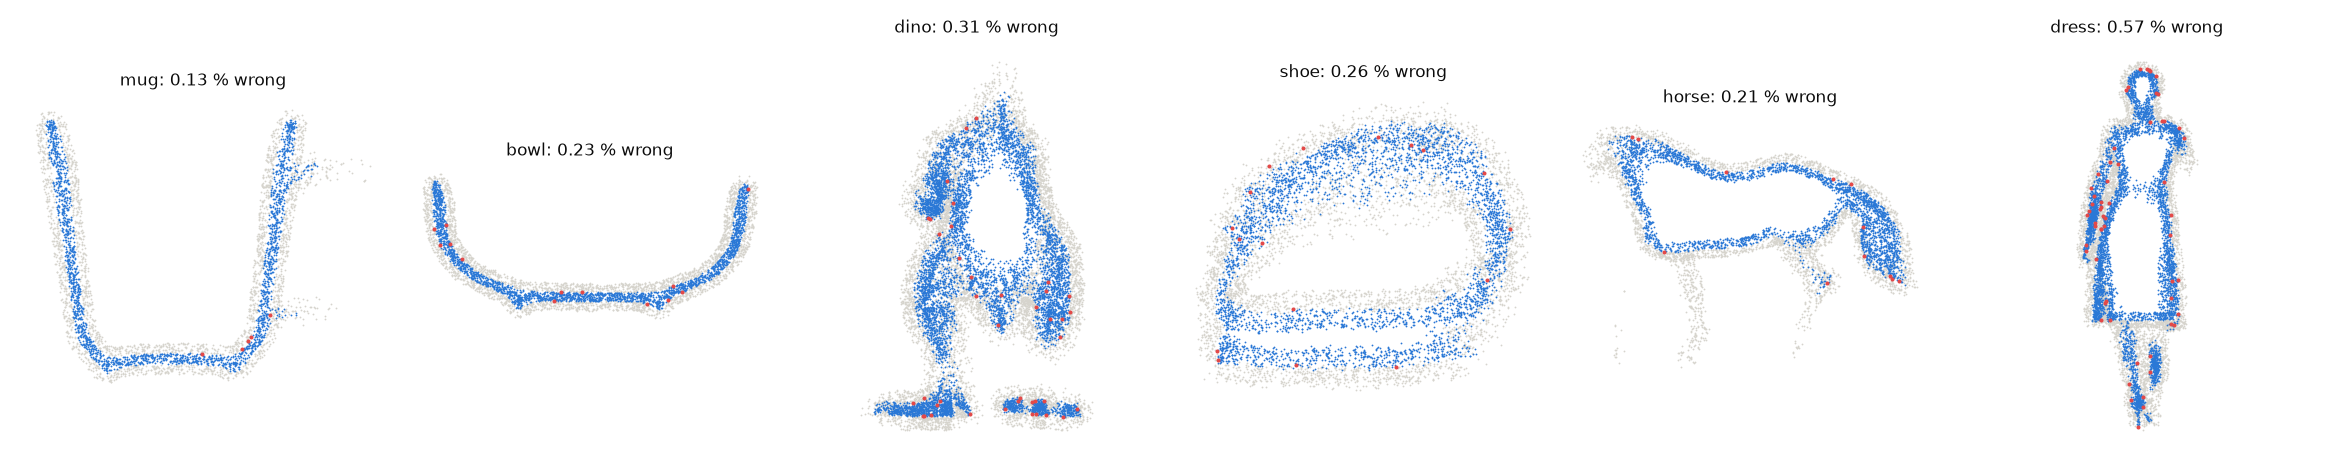
Wrong = of 1M points near the surface (±2 % diag) or 1M uniform in the box + 10 %, against the mesh. Filter boxes under each header take text or >x, <=x, !0; click a header to sort.
| object | layers | N | min area | MB | parts | near wrong > 0.1 % | > 0.2 % | > 0.3 % | uniform > 0.1 % | near wrong all, % | max err % diag | near ns/pt | uniform ns/pt | encode s | encode peak GB |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| gear | 512 | 64 | 0 | 0.00 | 2 | 4666 | 527 | 0 | 893 | 1.678 | 0.281 | 13.3 | 9.3 | nan | 0.5 |
| mug | 512 | 64 | 0 | 0.28 | 12 | 4 | 0 | 0 | 3 | 0.154 | 0.158 | 20.5 | 7.1 | 9 | 1.0 |
| bowl | 512 | 64 | 0 | 0.20 | 7 | 1 | 0 | 0 | 1 | 0.313 | 0.114 | 25.2 | 11.0 | 9 | 1.1 |
| dino | 512 | 64 | 0 | 0.62 | 45 | 82 | 6 | 0 | 3 | 0.393 | 0.266 | 14.3 | 2.7 | 7 | 1.0 |
| horse | 512 | 64 | 0 | 0.54 | 21 | 0 | 0 | 0 | 0 | 0.250 | 0.095 | 10.7 | 3.0 | 6 | 1.0 |
| shoe | 512 | 64 | 0 | 0.84 | 109 | 40 | 0 | 0 | 6 | 0.376 | 0.194 | 14.7 | 7.2 | 8 | 1.1 |
| dress | 512 | 64 | 0 | 0.62 | 31 | 182 | 5 | 0 | 3 | 0.993 | 0.237 | 13.8 | 3.4 | 9 | 1.1 |
| pan_holes | 512 | 64 | 0 | 0.49 | 59 | 48 | 18 | 7 | 4 | 0.427 | 0.362 | 24.9 | 8.4 | 11 | 1.1 |
| knot | 512 | 64 | 0 | 0.25 | 12 | 0 | 0 | 0 | 0 | 0.050 | 0.018 | 9.5 | 2.6 | 11 | 1.1 |
| spring | 512 | 64 | 0 | 0.18 | 5 | 0 | 0 | 0 | 0 | 0.435 | 0.083 | 23.2 | 12.2 | 9 | 1.0 |
| sponge | 512 | 64 | 0 | 0.05 | 96 | 14 | 0 | 0 | 7 | 0.398 | 0.182 | 14.7 | 10.9 | 2 | 1.3 |
| mug | 512 | 128 | 0 | 0.41 | 12 | 11 | 0 | 0 | 3 | 0.111 | 0.199 | 20.5 | 7.1 | 10 | 1.0 |
| bowl | 512 | 128 | 0 | 0.32 | 7 | 1 | 0 | 0 | 1 | 0.233 | 0.122 | 25.2 | 11.1 | 9 | 1.1 |
| dino | 512 | 128 | 0 | 0.81 | 45 | 74 | 1 | 0 | 3 | 0.375 | 0.206 | 14.4 | 2.7 | 7 | 1.0 |
| horse | 512 | 128 | 0 | 0.74 | 21 | 2 | 0 | 0 | 0 | 0.189 | 0.144 | 10.8 | 3.0 | 6 | 1.0 |
| shoe | 512 | 128 | 0 | 1.38 | 109 | 6 | 1 | 0 | 2 | 0.246 | 0.239 | 14.8 | 7.2 | 9 | 1.2 |
| dress | 512 | 128 | 0 | 0.98 | 31 | 146 | 2 | 0 | 3 | 0.887 | 0.216 | 14.6 | 3.7 | 9 | 1.1 |
| pan_holes | 512 | 128 | 0 | 0.79 | 59 | 31 | 14 | 5 | 3 | 0.332 | 0.335 | 24.9 | 8.4 | nan | 0.5 |
| knot | 512 | 128 | 0 | 0.31 | 12 | 0 | 0 | 0 | 0 | 0.039 | 0.026 | 9.5 | 2.6 | 10 | 1.1 |
| spring | 512 | 128 | 0 | 0.30 | 5 | 0 | 0 | 0 | 0 | 0.436 | 0.093 | 23.2 | 12.2 | 9 | 1.0 |
| sponge | 512 | 128 | 0 | 0.08 | 96 | 0 | 0 | 0 | 0 | 0.346 | 0.081 | 14.8 | 10.9 | 3 | 1.3 |
| gear | 512 | 128 | 0 | 0.00 | 2 | 548 | 0 | 0 | 104 | 0.649 | 0.171 | 12.7 | 9.0 | 0 | 1.0 |
| mug | 1024 | 64 | 0 | 0.36 | 13 | 0 | 0 | 0 | 0 | 0.115 | 0.088 | 23.9 | 8.2 | 33 | 1.3 |
| bowl | 1024 | 64 | 0 | 0.28 | 12 | 0 | 0 | 0 | 0 | 0.257 | 0.078 | 27.7 | 12.5 | 33 | 1.3 |
| dino | 1024 | 64 | 0 | 0.97 | 67 | 13 | 1 | 0 | 0 | 0.212 | 0.272 | 12.5 | 3.2 | 25 | 1.2 |
| horse | 1024 | 64 | 0 | 0.74 | 23 | 0 | 0 | 0 | 0 | 0.200 | 0.097 | 10.4 | 2.9 | 23 | 1.3 |
| shoe | 1024 | 64 | 0 | 1.33 | 164 | 34 | 0 | 0 | 3 | 0.324 | 0.193 | 15.1 | 7.9 | 31 | 1.4 |
| dress | 1024 | 64 | 0 | 0.95 | 43 | 19 | 0 | 0 | 0 | 0.691 | 0.195 | 11.1 | 3.0 | 32 | 1.4 |
| pan_holes | 1024 | 64 | 0 | 0.79 | 115 | 25 | 9 | 2 | 3 | 0.366 | 0.322 | 25.1 | 8.7 | 33 | 1.5 |
| knot | 1024 | 64 | 0 | 0.31 | 12 | 0 | 0 | 0 | 0 | 0.043 | 0.014 | 9.3 | 2.5 | 34 | 1.4 |
| spring | 1024 | 64 | 0 | 0.23 | 4 | 5 | 0 | 0 | 0 | 0.178 | 0.163 | 21.4 | 10.6 | 31 | 1.2 |
| sponge | 1024 | 64 | 0 | 0.05 | 96 | 23 | 0 | 0 | 7 | 0.298 | 0.154 | 15.6 | 11.3 | 12 | 1.7 |
| gear | 1024 | 64 | 0 | 0.00 | 2 | 4750 | 553 | 0 | 891 | 1.687 | 0.277 | 18.3 | 12.3 | 1 | 1.0 |
| mug | 1024 | 128 | 0 | 0.53 | 13 | 1 | 0 | 0 | 0 | 0.074 | 0.106 | 24.1 | 8.2 | 36 | 1.3 |
| bowl | 1024 | 128 | 0 | 0.46 | 12 | 0 | 0 | 0 | 0 | 0.148 | 0.039 | 27.6 | 12.5 | 34 | 1.3 |
| dino | 1024 | 128 | 0 | 1.28 | 67 | 12 | 2 | 0 | 0 | 0.178 | 0.237 | 11.0 | 2.6 | 27 | 1.3 |
| horse | 1024 | 128 | 0 | 1.05 | 23 | 2 | 0 | 0 | 0 | 0.136 | 0.184 | 10.5 | 2.9 | 25 | 1.3 |
| shoe | 1024 | 128 | 0 | 2.18 | 164 | 4 | 0 | 0 | 0 | 0.180 | 0.144 | 15.1 | 7.9 | 34 | 1.6 |
| dress | 1024 | 128 | 0 | 1.52 | 43 | 1 | 0 | 0 | 0 | 0.535 | 0.118 | 11.2 | 3.0 | 34 | 1.4 |
| pan_holes | 1024 | 128 | 0 | 1.28 | 115 | 21 | 10 | 0 | 1 | 0.259 | 0.297 | 25.2 | 8.7 | 37 | 1.7 |
| knot | 1024 | 128 | 0 | 0.40 | 12 | 0 | 0 | 0 | 0 | 0.033 | 0.009 | 9.3 | 2.5 | 40 | 1.5 |
| spring | 1024 | 128 | 0 | 0.42 | 5 | 0 | 0 | 0 | 0 | 0.150 | 0.066 | 21.1 | 10.5 | 33 | 1.2 |
| sponge | 1024 | 128 | 0 | 0.08 | 96 | 0 | 0 | 0 | 0 | 0.249 | 0.096 | 15.6 | 11.3 | 13 | 1.9 |
| gear | 1024 | 128 | 0 | 0.00 | 2 | 554 | 0 | 0 | 105 | 0.656 | 0.171 | 17.5 | 11.9 | 1 | 1.0 |
| mug | 1024 | 128 | 0.002 | 0.53 | 13 | 0 | 0 | 0 | 0 | 0.077 | 0.082 | 24.0 | 8.2 | 40 | 1.3 |
| mug | 1024 | 255 | 0 | 0.59 | 13 | 2 | 0 | 0 | 0 | 0.072 | 0.121 | 24.0 | 8.2 | 46 | 1.4 |
| bowl | 1024 | 128 | 0.002 | 0.46 | 12 | 0 | 0 | 0 | 0 | 0.146 | 0.035 | 27.7 | 12.5 | 35 | 1.3 |
| bowl | 1024 | 255 | 0 | 0.62 | 12 | 0 | 0 | 0 | 0 | 0.128 | 0.042 | 27.7 | 12.5 | 42 | 1.4 |
| dino | 1024 | 128 | 0.002 | 1.27 | 59 | 22 | 3 | 0 | 1 | 0.184 | 0.289 | 12.3 | 2.7 | 27 | 1.3 |
| dino | 1024 | 255 | 0 | 1.35 | 67 | 14 | 0 | 0 | 0 | 0.181 | 0.190 | 11.0 | 2.6 | 31 | 1.4 |
| horse | 1024 | 128 | 0.002 | 1.05 | 21 | 4 | 0 | 0 | 0 | 0.136 | 0.138 | 10.1 | 2.7 | 25 | 1.3 |
| horse | 1024 | 255 | 0 | 1.25 | 23 | 2 | 0 | 0 | 0 | 0.118 | 0.141 | 10.2 | 2.7 | 28 | 1.4 |
| shoe | 1024 | 128 | 0.002 | 2.00 | 57 | 198 | 78 | 14 | 13 | 0.222 | 0.368 | 14.5 | 6.2 | 33 | 1.3 |
| shoe | 1024 | 255 | 0 | 3.15 | 164 | 2 | 0 | 0 | 0 | 0.145 | 0.107 | 15.2 | 7.9 | 40 | 2.0 |
| dress | 1024 | 128 | 0.002 | 1.52 | 41 | 7 | 0 | 0 | 0 | 0.546 | 0.158 | 12.5 | 3.5 | 34 | 1.4 |
| dress | 1024 | 255 | 0 | 2.04 | 43 | 1 | 0 | 0 | 0 | 0.475 | 0.121 | 12.5 | 3.6 | 38 | 1.5 |
| pan_holes | 1024 | 128 | 0.002 | 1.18 | 56 | 31 | 11 | 1 | 1 | 0.268 | 0.301 | 24.9 | 8.1 | 35 | 1.5 |
| pan_holes | 1024 | 255 | 0 | 1.78 | 115 | 23 | 11 | 1 | 1 | 0.226 | 0.307 | 25.2 | 8.7 | 42 | 2.3 |
| knot | 1024 | 128 | 0.002 | 0.40 | 12 | 0 | 0 | 0 | 0 | 0.032 | 0.012 | 9.3 | 2.5 | 38 | 1.5 |
| knot | 1024 | 255 | 0 | 0.41 | 12 | 0 | 0 | 0 | 0 | 0.033 | 0.014 | 9.3 | 2.5 | 49 | 1.6 |
| spring | 1024 | 128 | 0.002 | 0.42 | 5 | 0 | 0 | 0 | 0 | 0.151 | 0.028 | 21.0 | 10.5 | 33 | 1.2 |
| spring | 1024 | 255 | 0 | 0.48 | 5 | 0 | 0 | 0 | 0 | 0.149 | 0.022 | 21.0 | 10.5 | 36 | 1.2 |
| sponge | 1024 | 128 | 0.002 | 0.08 | 96 | 0 | 0 | 0 | 0 | 0.245 | 0.077 | 15.6 | 11.3 | 14 | 1.9 |
| sponge | 1024 | 255 | 0 | 0.10 | 96 | 0 | 0 | 0 | 0 | 0.245 | 0.051 | 15.5 | 11.3 | 17 | 2.1 |
| gear | 1024 | 128 | 0.002 | 0.00 | 2 | 566 | 0 | 0 | 105 | 0.663 | 0.173 | 17.5 | 11.9 | 1 | 1.0 |
| gear | 1024 | 255 | 0 | 0.00 | 2 | 210 | 0 | 0 | 32 | 0.441 | 0.150 | 17.9 | 12.1 | 1 | 1.1 |
table: inside at the two neighbouring layer centres decides where they agree, else each part's two rings blended at the query height; nearest: the ring set of the nearest layer centre, one parity per part (height error at most half a layer).
| object | NT | rule | near wrong > 0.1 % | > 0.2 % | uniform > 0.1 % | near wrong all, % | near ns/pt | uniform ns/pt |
|---|---|---|---|---|---|---|---|---|
| mug | 256 | table | 1 | 0 | 0 | 0.090 | 17.8 | 6.3 |
| mug | 256 | nearest | 1 | 0 | 0 | 0.147 | 8.9 | 3.5 |
| mug | 512 | table | 0 | 0 | 0 | 0.080 | 23.9 | 8.1 |
| mug | 512 | nearest | 0 | 0 | 0 | 0.139 | 12.1 | 4.6 |
| mug | 1024 | table | 0 | 0 | 0 | 0.079 | 26.4 | 8.8 |
| mug | 1024 | nearest | 0 | 0 | 0 | 0.137 | 13.4 | 5.1 |
| bowl | 256 | table | 0 | 0 | 0 | 0.182 | 20.1 | 8.8 |
| bowl | 256 | nearest | 0 | 0 | 0 | 0.256 | 10.2 | 4.5 |
| bowl | 512 | table | 0 | 0 | 0 | 0.144 | 27.7 | 12.5 |
| bowl | 512 | nearest | 0 | 0 | 0 | 0.220 | 13.9 | 6.3 |
| bowl | 1024 | table | 0 | 0 | 0 | 0.141 | 30.6 | 13.8 |
| bowl | 1024 | nearest | 0 | 0 | 0 | 0.215 | 15.4 | 7.0 |
| dino | 256 | table | 10 | 1 | 0 | 0.196 | 10.8 | 3.0 |
| dino | 256 | nearest | 13 | 2 | 0 | 0.331 | 6.3 | 1.6 |
| dino | 512 | table | 10 | 1 | 0 | 0.189 | 10.9 | 2.6 |
| dino | 512 | nearest | 13 | 2 | 0 | 0.325 | 7.4 | 1.7 |
| dino | 1024 | table | 10 | 1 | 0 | 0.188 | 13.8 | 2.8 |
| dino | 1024 | nearest | 13 | 2 | 0 | 0.323 | 9.2 | 1.8 |
| horse | 256 | table | 3 | 0 | 0 | 0.154 | 7.8 | 2.3 |
| horse | 256 | nearest | 4 | 1 | 0 | 0.244 | 5.0 | 1.5 |
| horse | 512 | table | 2 | 0 | 0 | 0.132 | 9.7 | 2.5 |
| horse | 512 | nearest | 4 | 1 | 0 | 0.224 | 6.5 | 1.6 |
| horse | 1024 | table | 2 | 0 | 0 | 0.129 | 12.2 | 2.7 |
| horse | 1024 | nearest | 4 | 1 | 0 | 0.222 | 7.9 | 1.8 |
| shoe | 256 | table | 7 | 0 | 2 | 0.221 | 13.6 | 7.5 |
| shoe | 256 | nearest | 7 | 0 | 2 | 0.289 | 8.7 | 4.8 |
| shoe | 512 | table | 3 | 0 | 0 | 0.182 | 15.2 | 7.9 |
| shoe | 512 | nearest | 3 | 0 | 0 | 0.258 | 10.4 | 5.2 |
| shoe | 1024 | table | 3 | 0 | 0 | 0.181 | 17.4 | 8.6 |
| shoe | 1024 | nearest | 3 | 0 | 0 | 0.256 | 12.0 | 5.7 |
| dress | 256 | table | 13 | 0 | 0 | 0.583 | 10.5 | 3.3 |
| dress | 256 | nearest | 8 | 0 | 0 | 0.613 | 5.7 | 1.8 |
| dress | 512 | table | 3 | 0 | 0 | 0.533 | 11.1 | 3.0 |
| dress | 512 | nearest | 2 | 0 | 0 | 0.570 | 7.4 | 2.0 |
| dress | 1024 | table | 3 | 0 | 0 | 0.529 | 14.5 | 3.5 |
| dress | 1024 | nearest | 2 | 0 | 0 | 0.570 | 9.6 | 2.2 |
| pan_holes | 256 | table | 33 | 13 | 1 | 0.291 | 20.3 | 7.6 |
| pan_holes | 256 | nearest | 30 | 11 | 1 | 0.428 | 11.1 | 4.8 |
| pan_holes | 512 | table | 31 | 13 | 1 | 0.255 | 25.2 | 8.7 |
| pan_holes | 512 | nearest | 28 | 11 | 1 | 0.395 | 14.1 | 5.8 |
| pan_holes | 1024 | table | 31 | 13 | 1 | 0.257 | 30.9 | 9.9 |
| pan_holes | 1024 | nearest | 29 | 11 | 1 | 0.393 | 17.3 | 6.6 |
| knot | 256 | table | 0 | 0 | 0 | 0.033 | 8.3 | 2.5 |
| knot | 256 | nearest | 0 | 0 | 0 | 0.122 | 5.3 | 1.5 |
| knot | 512 | table | 0 | 0 | 0 | 0.033 | 9.3 | 2.5 |
| knot | 512 | nearest | 0 | 0 | 0 | 0.122 | 6.2 | 1.4 |
| knot | 1024 | table | 0 | 0 | 0 | 0.033 | 9.8 | 2.3 |
| knot | 1024 | nearest | 0 | 0 | 0 | 0.122 | 6.8 | 1.5 |
| spring | 256 | table | 0 | 0 | 0 | 0.163 | 13.0 | 6.7 |
| spring | 256 | nearest | 0 | 0 | 0 | 0.292 | 6.4 | 3.6 |
| spring | 512 | table | 0 | 0 | 0 | 0.146 | 21.1 | 10.5 |
| spring | 512 | nearest | 0 | 0 | 0 | 0.292 | 10.6 | 5.5 |
| spring | 1024 | table | 0 | 0 | 0 | 0.143 | 34.6 | 17.2 |
| spring | 1024 | nearest | 0 | 0 | 0 | 0.291 | 17.3 | 8.9 |
| sponge | 256 | table | 0 | 0 | 0 | 0.250 | 15.1 | 11.1 |
| sponge | 256 | nearest | 0 | 0 | 0 | 0.250 | 10.2 | 7.4 |
| sponge | 512 | table | 0 | 0 | 0 | 0.251 | 15.6 | 11.3 |
| sponge | 512 | nearest | 0 | 0 | 0 | 0.251 | 11.3 | 7.9 |
| sponge | 1024 | table | 0 | 0 | 0 | 0.252 | 15.8 | 11.4 |
| sponge | 1024 | nearest | 0 | 0 | 0 | 0.252 | 11.6 | 8.1 |
| gear | 256 | table | 3744 | 734 | 630 | 1.166 | 12.5 | 8.3 |
| gear | 256 | nearest | 3744 | 734 | 630 | 1.166 | 6.3 | 4.2 |
| gear | 512 | table | 547 | 0 | 105 | 0.657 | 17.5 | 11.9 |
| gear | 512 | nearest | 547 | 0 | 105 | 0.657 | 8.8 | 6.0 |
| gear | 1024 | table | 170 | 0 | 41 | 0.626 | 20.6 | 13.7 |
| gear | 1024 | nearest | 170 | 0 | 41 | 0.626 | 10.3 | 6.9 |
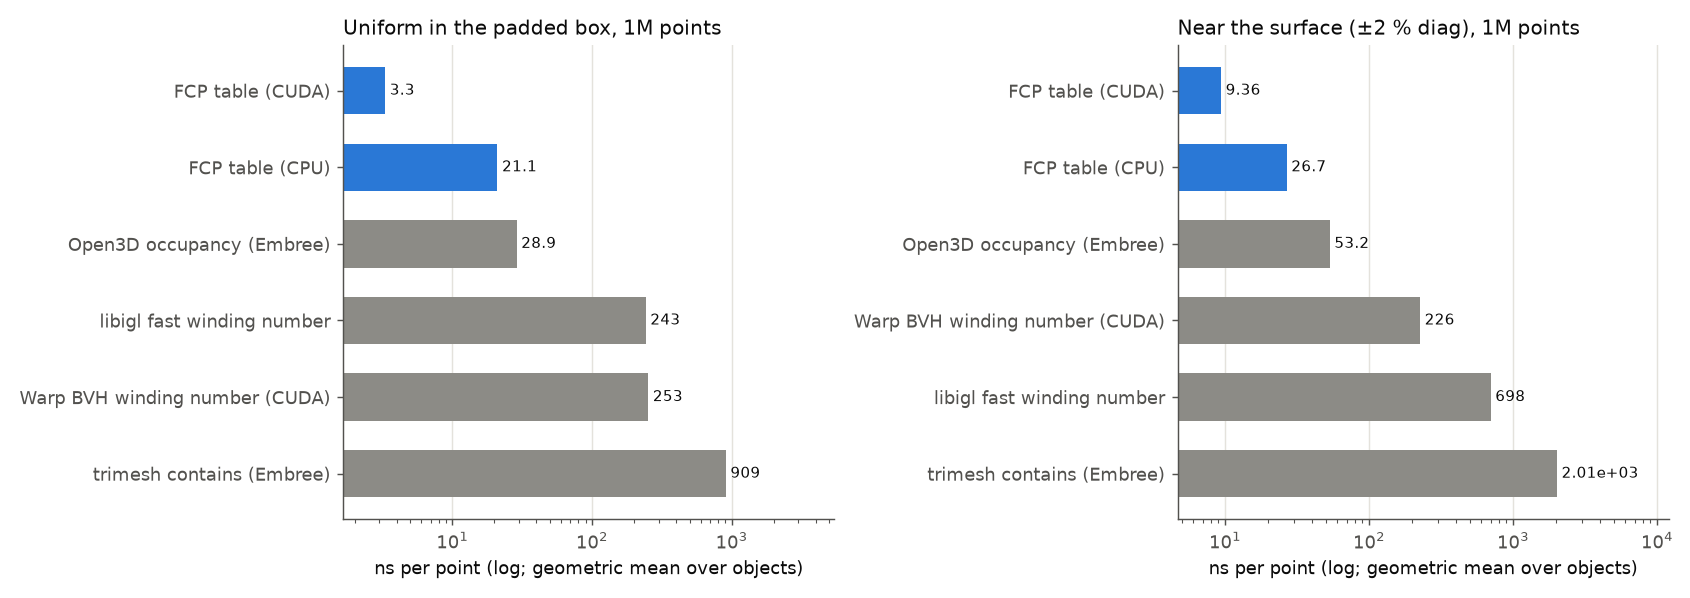
| method | device | mug ns/pt | bowl ns/pt | dino ns/pt | shoe ns/pt | horse ns/pt | dress ns/pt | geo-mean ns/pt | × vs Open3D | build ms (mean) | wrong vs mesh % | wrong vs decoded % |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| FCP table (CUDA) | gpu | 12.1 | 14 | 7.49 | 10.4 | 6.52 | 7.79 | 9.36 | 5.7 | 189 | 0.29 | |
| FCP table (CPU) | cpu | 28.2 | 26.2 | 28.4 | 35.7 | 21.4 | 22.8 | 26.7 | 2.0 | 189 | 0.29 | |
| Open3D occupancy (Embree) | cpu | 56.1 | 55.5 | 48.4 | 55 | 40.5 | 67.5 | 53.2 | 1.0 | 0.702 | 0.00 | |
| Warp BVH winding number (CUDA) | gpu | 113 | 160 | 218 | 262 | 154 | 827 | 226 | 0.2 | 8.25 | 0.00 | |
| libigl fast winding number | cpu | 863 | 714 | 609 | 942 | 547 | 597 | 698 | 0.1 | 31.9 | 0.00 |
| method | device | mug ns/pt | bowl ns/pt | dino ns/pt | shoe ns/pt | horse ns/pt | dress ns/pt | geo-mean ns/pt | × vs Open3D | build ms (mean) | wrong vs mesh % | wrong vs decoded % |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| FCP table (CUDA) | gpu | 4.7 | 6.39 | 2 | 5.89 | 1.84 | 2 | 3.3 | 8.7 | 189 | 0.04 | |
| FCP table (CPU) | cpu | 23.1 | 15.9 | 21.2 | 24.3 | 23.3 | 19.7 | 21.1 | 1.4 | 189 | 0.04 | |
| Open3D occupancy (Embree) | cpu | 32.8 | 32.8 | 20.9 | 32.4 | 22.4 | 35.6 | 28.9 | 1.0 | 0.702 | 0.00 | |
| libigl fast winding number | cpu | 377 | 268 | 115 | 385 | 171 | 267 | 243 | 0.1 | 31.9 | 0.00 | |
| Warp BVH winding number (CUDA) | gpu | 120 | 242 | 221 | 247 | 161 | 1.03e+03 | 253 | 0.1 | 8.25 | 0.00 |
| method | device | mug ns/pt | bowl ns/pt | dino ns/pt | shoe ns/pt | horse ns/pt | dress ns/pt | geo-mean ns/pt | × vs Open3D | build ms (mean) | wrong vs mesh % | wrong vs decoded % |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| FCP table (CUDA) | gpu | 13.8 | 17.2 | 14.2 | 15.7 | 10.9 | 13.6 | 14.1 | 5.8 | 189 | 0.28 | 0.38 |
| FCP table (CPU) | cpu | 25.2 | 24.8 | 24.4 | 34.9 | 18.2 | 600 | 42.4 | 1.9 | 189 | 0.28 | 0.38 |
| Open3D occupancy (Embree) | cpu | 85.3 | 91.1 | 78.4 | 87.2 | 63.9 | 90.2 | 82.1 | 1.0 | 0.702 | 0.00 | 0.43 |
| Warp BVH winding number (CUDA) | gpu | 125 | 154 | 211 | 250 | 162 | 867 | 229 | 0.4 | 8.25 | 0.00 | 0.43 |
| trimesh contains (Embree) | cpu | 2.08e+03 | 1.92e+03 | 1.71e+03 | 2.22e+03 | 1.52e+03 | 2.9e+03 | 2.01e+03 | 0.0 | 80.7 | 0.00 | 0.43 |
| libigl fast winding number | cpu | 1.41e+03 | 1.57e+03 | 1.83e+03 | 2.3e+03 | 1.39e+03 | 1.49e+04 | 2.4e+03 | 0.0 | 31.9 | 0.00 | 0.43 |
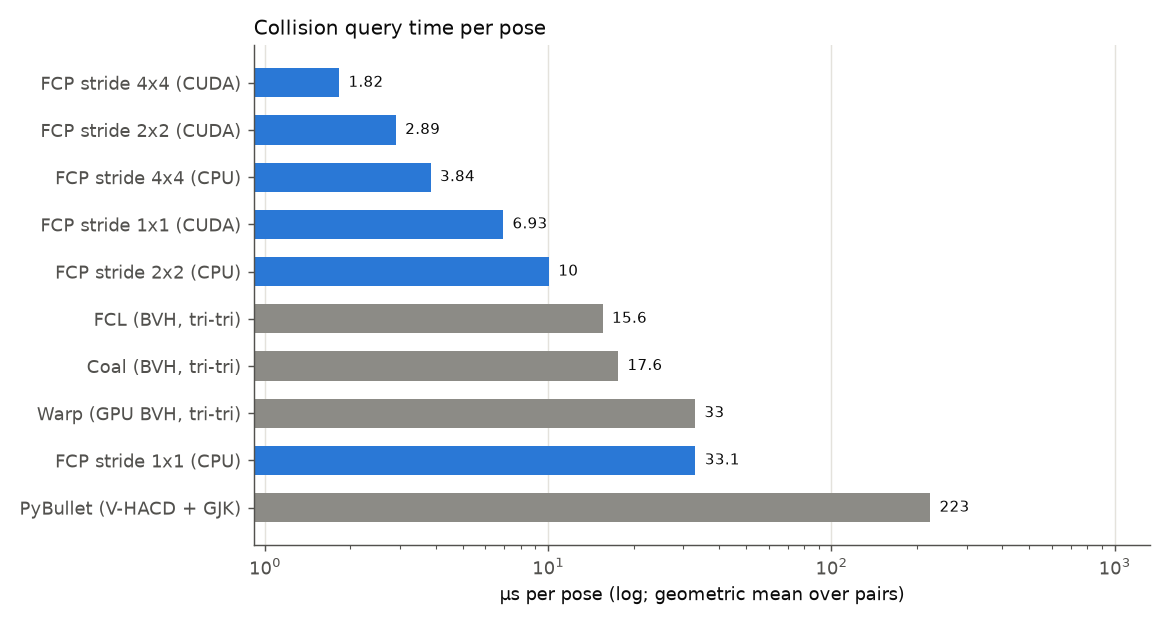
| method | device | mug-bowl µs/pose | dino-horse µs/pose | shoe-horse µs/pose | mug-mug µs/pose | dress-horse µs/pose | geo-mean µs/pose | × vs Coal | build ms (mean) | accuracy vs mesh % | missed | false | accuracy vs decoded % |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| FCP stride 4x4 (CUDA) | gpu | 3.96 | 1.2 | 1.32 | 3 | 1.08 | 1.82 | 9.7 | 401.5 | 99.71 | 29 | 0 | 99.74 |
| FCP stride 2x2 (CUDA) | gpu | 5.34 | 2.25 | 2.5 | 3.55 | 1.91 | 2.89 | 6.1 | 401.5 | 99.89 | 11 | 0 | 99.92 |
| FCP stride 4x4 (CPU) | cpu | 2.68 | 5.31 | 5.22 | 2.98 | 3.78 | 3.84 | 4.6 | 401.5 | 99.71 | 29 | 0 | 99.74 |
| FCP stride 1x1 (CUDA) | gpu | 8.74 | 8.03 | 7.26 | 5.43 | 5.76 | 6.93 | 2.5 | 401.5 | 99.96 | 4 | 0 | 99.97 |
| FCP stride 2x2 (CPU) | cpu | 8.27 | 16.1 | 13 | 5.44 | 10.9 | 10 | 1.8 | 401.5 | 99.89 | 11 | 0 | 99.92 |
| FCL (BVH, tri-tri) | cpu | 23.5 | 11.5 | 13.1 | 20.1 | 12.8 | 15.6 | 1.1 | 358.2 | 100.00 | 0 | 0 | 99.93 |
| Coal (BVH, tri-tri) | cpu | 25.4 | 12.8 | 14.7 | 23.5 | 15.1 | 17.6 | 1.0 | 260.4 | 100.00 | 0 | 0 | 99.93 |
| Warp (GPU BVH, tri-tri) | gpu | 21 | 15.4 | 27.3 | 19.8 | 224 | 33 | 0.5 | 4.236 | 100.00 | 0 | 0 | 99.93 |
| FCP stride 1x1 (CPU) | cpu | 28 | 53.5 | 37.2 | 20.1 | 35.4 | 33.1 | 0.5 | 401.5 | 99.96 | 4 | 0 | 99.97 |
| PyBullet (V-HACD + GJK) | cpu | 337 | 157 | 184 | 357 | 159 | 223 | 0.1 | 0.06119 | 98.70 | 0 | 130 | 98.65 |
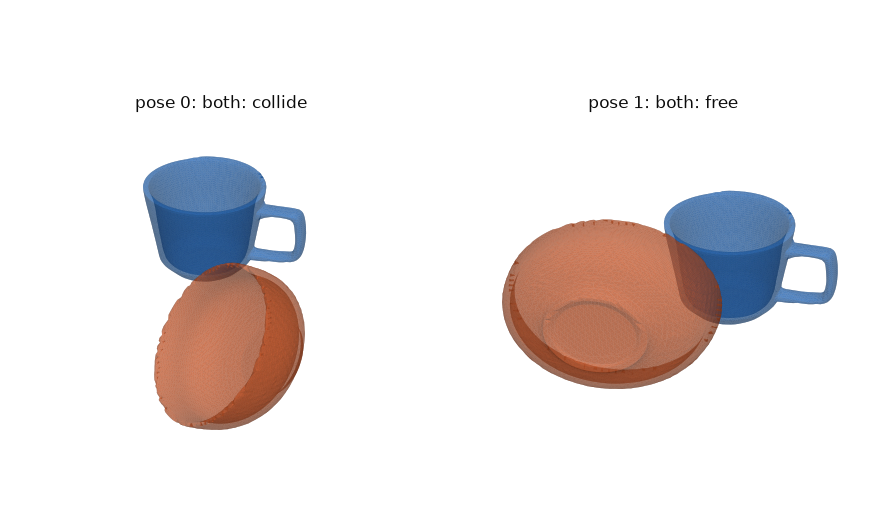
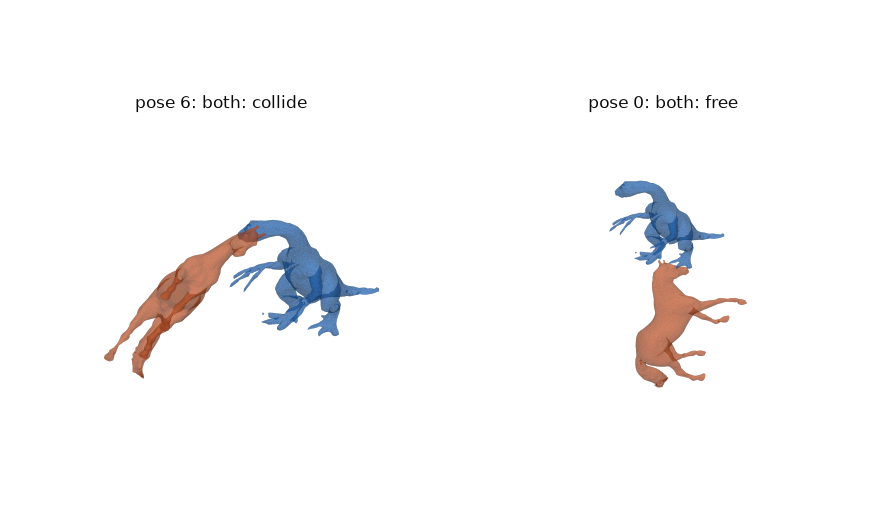
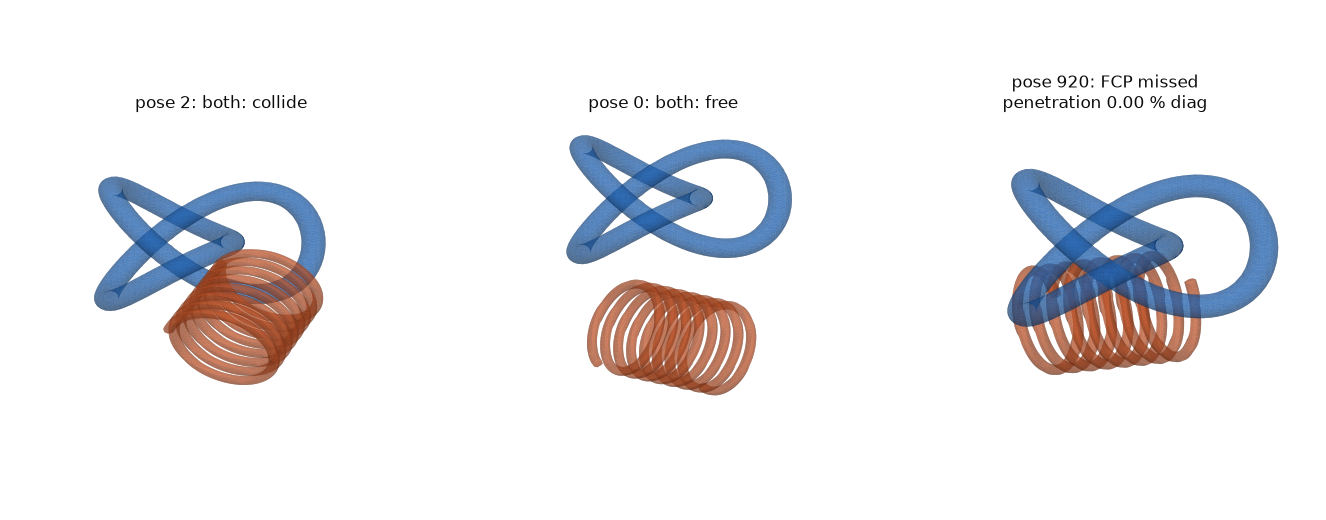
mug-bowl: 8454 / 14030 faces, 66 % of 2000 poses collide; dino-horse: 19690 / 13840 faces, 32 % of 2000 poses collide; shoe-horse: 24314 / 13840 faces, 39 % of 2000 poses collide; mug-mug: 8454 / 8454 faces, 62 % of 2000 poses collide; dress-horse: 444020 / 13840 faces, 31 % of 2000 poses collide

make_shapes.py): a trefoil knot tube (several rings per layer, crossings on every ray), a coil
spring of 8 turns (16 rings per layer, a deep open concavity), a level-2 Menger sponge (square holes along
every axis, genus 72) and a 24-tooth gear with a bore (sharp corners: harmonics far beyond N). Pairs: each with
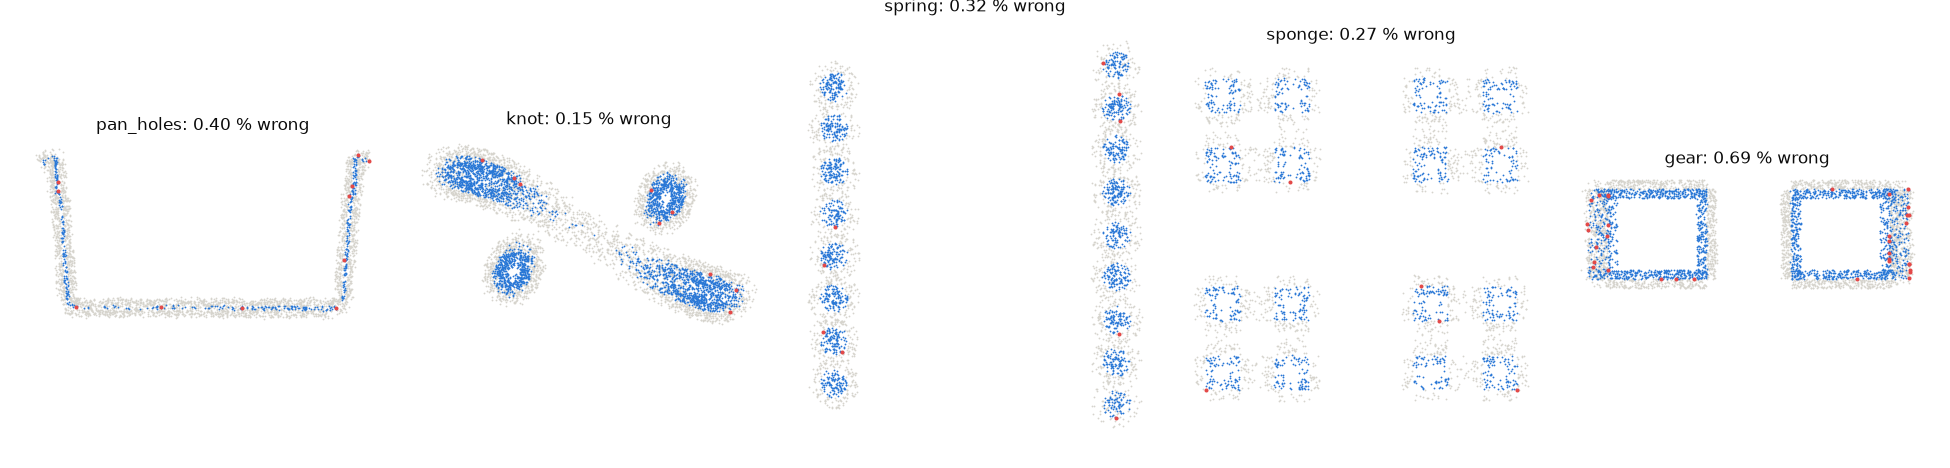
itself, pan–mug and knot–spring. The BVH methods slow down most here (Warp up to 680 ns per point on the spring, libigl up
to 1.8 µs on the gear and pan); FCP stays at 6–14 ns.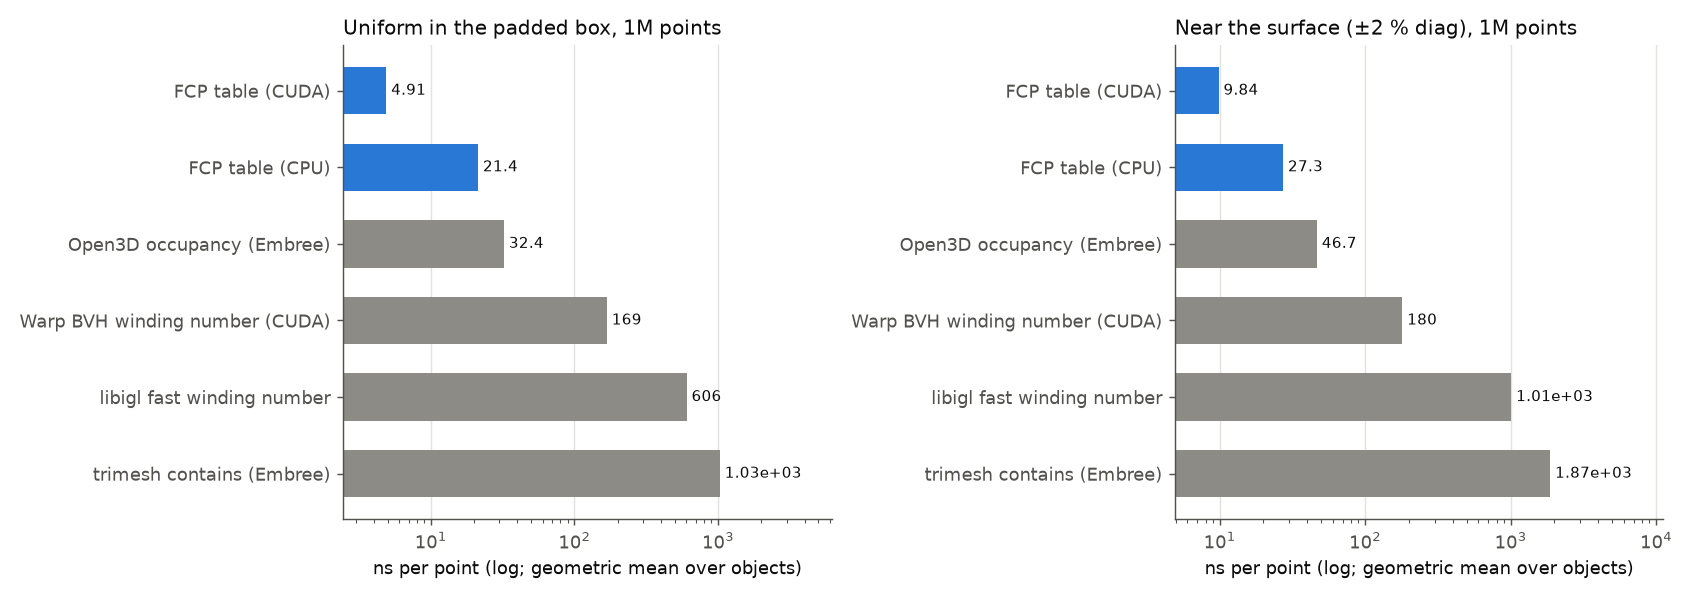
| method | device | pan_holes ns/pt | knot ns/pt | spring ns/pt | sponge ns/pt | gear ns/pt | geo-mean ns/pt | × vs Open3D | build ms (mean) | wrong vs mesh % | wrong vs decoded % |
|---|---|---|---|---|---|---|---|---|---|---|---|
| FCP table (CUDA) | gpu | 14.2 | 6.12 | 10.6 | 11.3 | 8.82 | 9.84 | 4.7 | 305 | 0.35 | |
| FCP table (CPU) | cpu | 32.4 | 27.5 | 22.4 | 48.7 | 15.6 | 27.3 | 1.7 | 305 | 0.35 | |
| Open3D occupancy (Embree) | cpu | 48.8 | 50.4 | 57.9 | 49.8 | 31.3 | 46.7 | 1.0 | 0.29 | 0.00 | |
| Warp BVH winding number (CUDA) | gpu | 169 | 293 | 683 | 133 | 42.2 | 180 | 0.3 | 2.34 | 0.00 | |
| libigl fast winding number | cpu | 1.55e+03 | 458 | 563 | 1.5e+03 | 1.76e+03 | 1.01e+03 | 0.0 | 10.7 | 0.00 |
| method | device | pan_holes ns/pt | knot ns/pt | spring ns/pt | sponge ns/pt | gear ns/pt | geo-mean ns/pt | × vs Open3D | build ms (mean) | wrong vs mesh % | wrong vs decoded % |
|---|---|---|---|---|---|---|---|---|---|---|---|
| FCP table (CUDA) | gpu | 6.08 | 1.59 | 5.64 | 8.64 | 6.02 | 4.91 | 6.6 | 305 | 0.08 | |
| FCP table (CPU) | cpu | 21.4 | 22.4 | 21.7 | 34.2 | 12.6 | 21.4 | 1.5 | 305 | 0.08 | |
| Open3D occupancy (Embree) | cpu | 31.4 | 25.7 | 39.2 | 45.3 | 24.9 | 32.4 | 1.0 | 0.29 | 0.00 | |
| Warp BVH winding number (CUDA) | gpu | 146 | 378 | 599 | 105 | 39.4 | 169 | 0.2 | 2.34 | 0.00 | |
| libigl fast winding number | cpu | 1.07e+03 | 157 | 237 | 1.37e+03 | 1.5e+03 | 606 | 0.1 | 10.7 | 0.00 |
| method | device | pan_holes ns/pt | knot ns/pt | spring ns/pt | sponge ns/pt | gear ns/pt | geo-mean ns/pt | × vs Open3D | build ms (mean) | wrong vs mesh % | wrong vs decoded % |
|---|---|---|---|---|---|---|---|---|---|---|---|
| FCP table (CUDA) | gpu | 20 | 9.35 | 12 | 15.9 | 11.5 | 13.3 | 5.6 | 305 | 0.34 | 0.46 |
| FCP table (CPU) | cpu | 36 | 18.4 | 20.1 | 37.7 | 15.6 | 23.9 | 3.1 | 305 | 0.34 | 0.46 |
| Open3D occupancy (Embree) | cpu | 77.8 | 81.8 | 93.2 | 80.3 | 49.5 | 74.9 | 1.0 | 0.29 | 0.00 | 0.50 |
| Warp BVH winding number (CUDA) | gpu | 195 | 276 | 632 | 184 | 43.4 | 193 | 0.4 | 2.34 | 0.00 | 0.50 |
| trimesh contains (Embree) | cpu | 2.16e+03 | 1.66e+03 | 2.57e+03 | 2.31e+03 | 1.08e+03 | 1.87e+03 | 0.0 | 22 | 0.00 | 0.50 |
| libigl fast winding number | cpu | 2.66e+03 | 1.91e+03 | 3.37e+03 | 1.6e+03 | 1.85e+03 | 2.19e+03 | 0.0 | 10.7 | 0.00 | 0.50 |
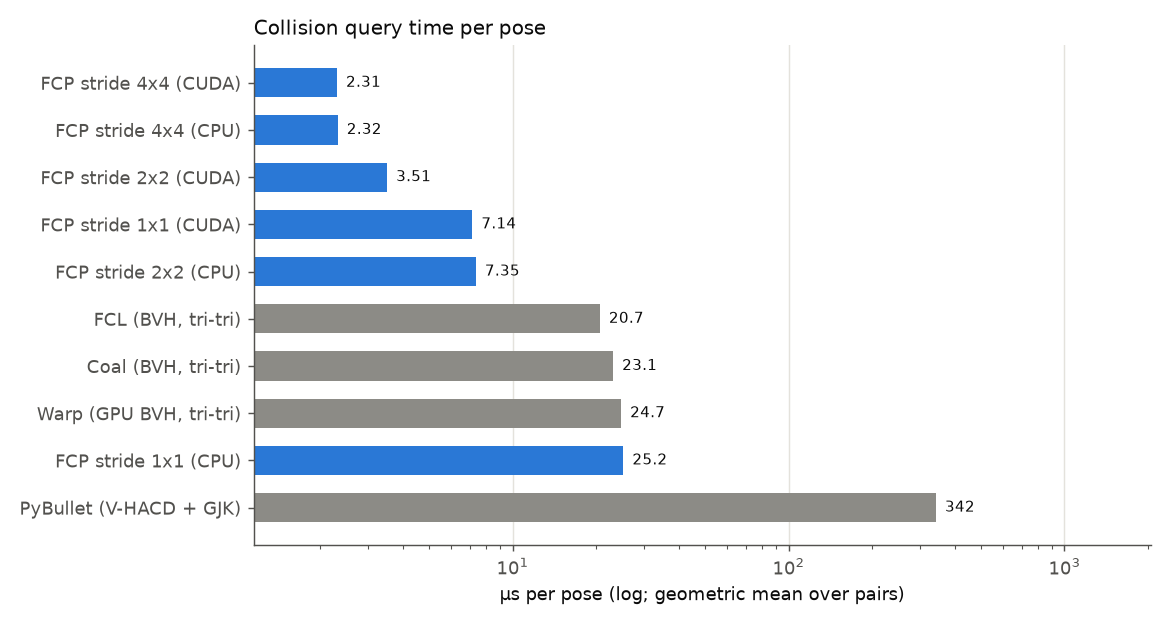
| method | device | spring-spring µs/pose | knot-knot µs/pose | sponge-sponge µs/pose | gear-gear µs/pose | pan_holes-mug µs/pose | knot-spring µs/pose | geo-mean µs/pose | × vs Coal | build ms (mean) | accuracy vs mesh % | missed | false | accuracy vs decoded % |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| FCP stride 4x4 (CUDA) | gpu | 3.04 | 1.3 | 4.64 | 1.44 | 1.92 | 2.99 | 2.31 | 10.0 | 560.2 | 99.54 | 55 | 0 | 99.62 |
| FCP stride 4x4 (CPU) | cpu | 0.644 | 3.77 | 7.63 | 0.802 | 5.46 | 1.94 | 2.32 | 9.9 | 560.2 | 99.54 | 55 | 0 | 99.62 |
| FCP stride 2x2 (CUDA) | gpu | 3.68 | 2.49 | 6.81 | 1.99 | 3.47 | 4.3 | 3.51 | 6.6 | 560.2 | 99.80 | 24 | 0 | 99.87 |
| FCP stride 1x1 (CUDA) | gpu | 4.47 | 8.2 | 17.5 | 2.88 | 10.2 | 7.06 | 7.14 | 3.2 | 560.2 | 99.91 | 11 | 0 | 99.95 |
| FCP stride 2x2 (CPU) | cpu | 1.79 | 13.7 | 22.8 | 2.62 | 15.4 | 7 | 7.35 | 3.1 | 560.2 | 99.80 | 24 | 0 | 99.87 |
| FCL (BVH, tri-tri) | cpu | 24.5 | 15.8 | 33.6 | 15.3 | 20.9 | 18.8 | 20.7 | 1.1 | 175.6 | 100.00 | 0 | 0 | 99.89 |
| Coal (BVH, tri-tri) | cpu | 26 | 16.5 | 42.3 | 16.2 | 26.2 | 19.8 | 23.1 | 1.0 | 130.6 | 100.00 | 0 | 0 | 99.89 |
| Warp (GPU BVH, tri-tri) | gpu | 46.7 | 23.2 | 13.8 | 11.4 | 44.9 | 29.8 | 24.7 | 0.9 | 3.414 | 100.00 | 0 | 0 | 99.89 |
| FCP stride 1x1 (CPU) | cpu | 6.3 | 50.1 | 74.1 | 9.52 | 46.5 | 24.6 | 25.2 | 0.9 | 560.2 | 99.91 | 11 | 0 | 99.95 |
| PyBullet (V-HACD + GJK) | cpu | 491 | 183 | 715 | 296 | 294 | 283 | 342 | 0.1 | 0.05518 | 98.73 | 0 | 152 | 98.62 |
spring-spring: 76796 / 76796 faces, 77 % of 2000 poses collide; knot-knot: 28800 / 28800 faces, 52 % of 2000 poses collide; sponge-sponge: 1300 / 1300 faces, 75 % of 2000 poses collide; gear-gear: 992 / 992 faces, 76 % of 2000 poses collide; pan_holes-mug: 16092 / 8454 faces, 54 % of 2000 poses collide; knot-spring: 28800 / 76796 faces, 59 % of 2000 poses collide
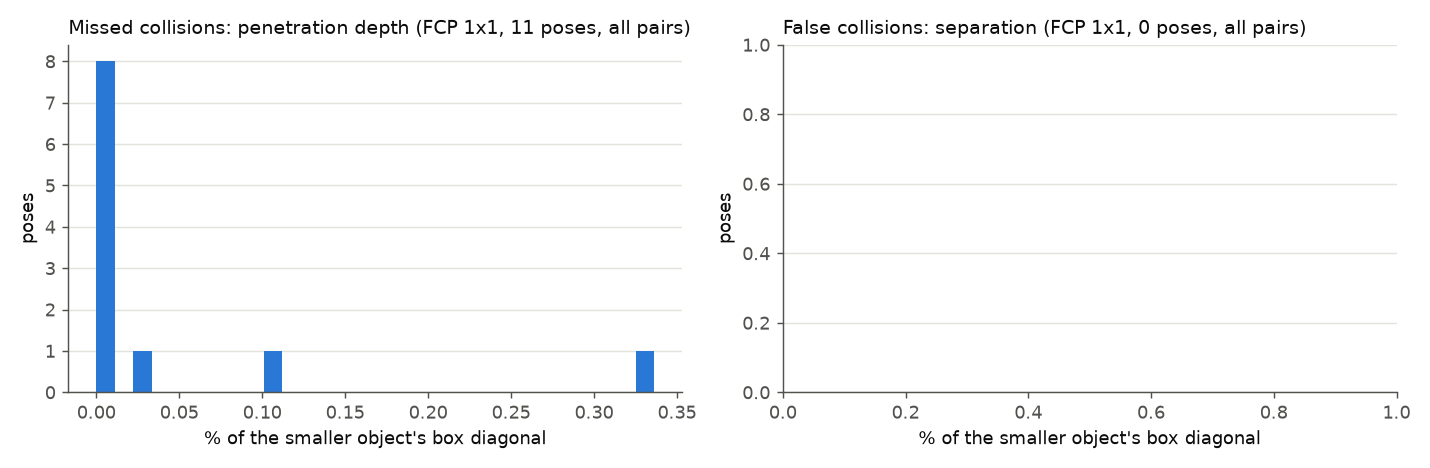


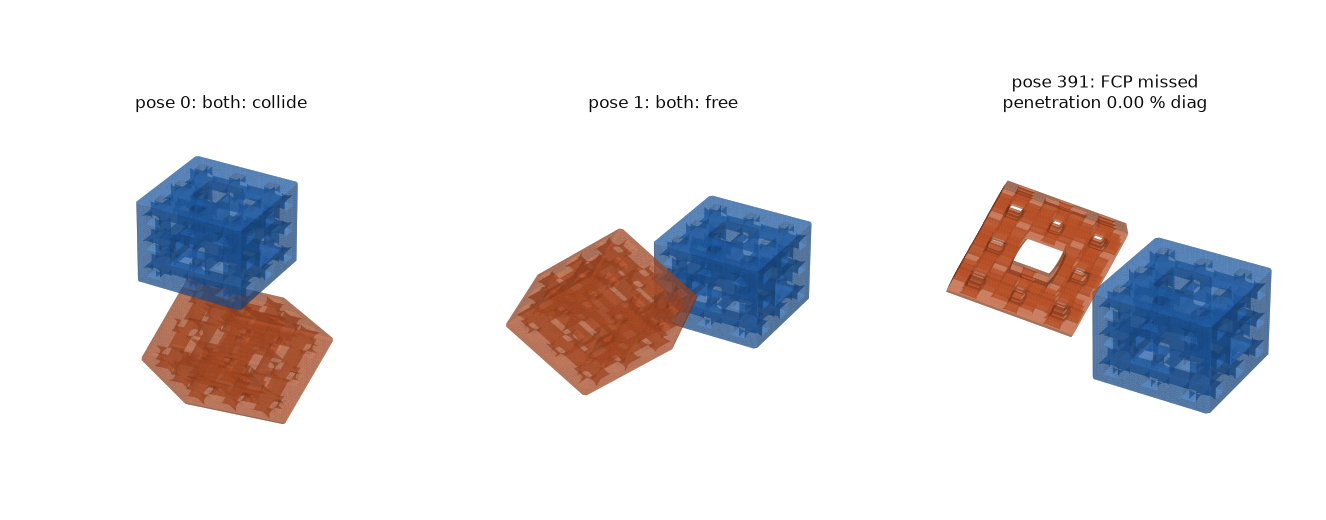

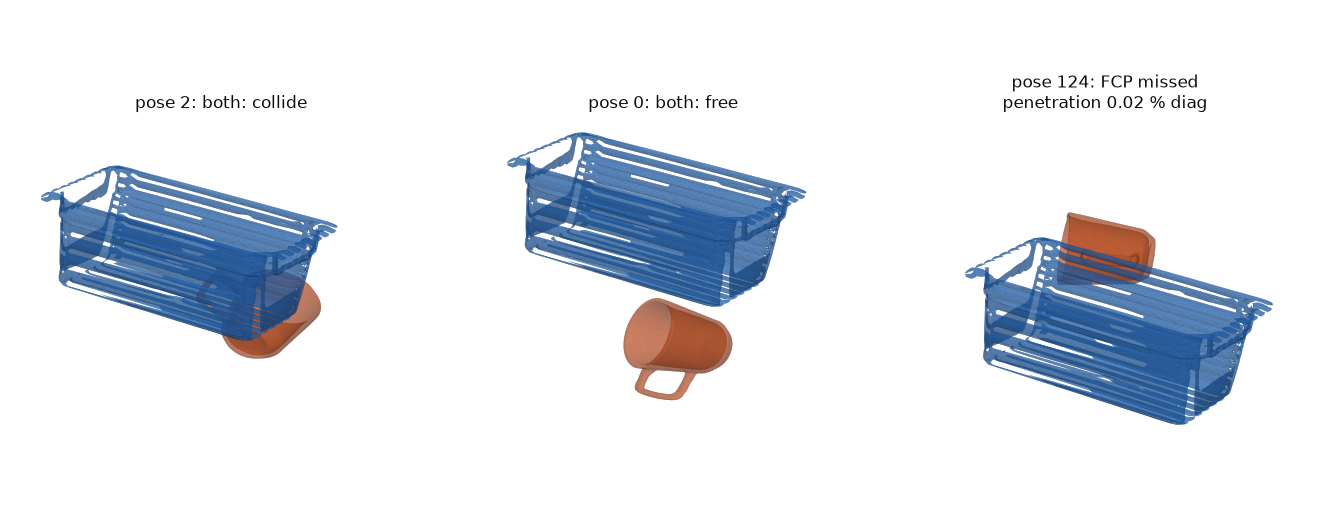
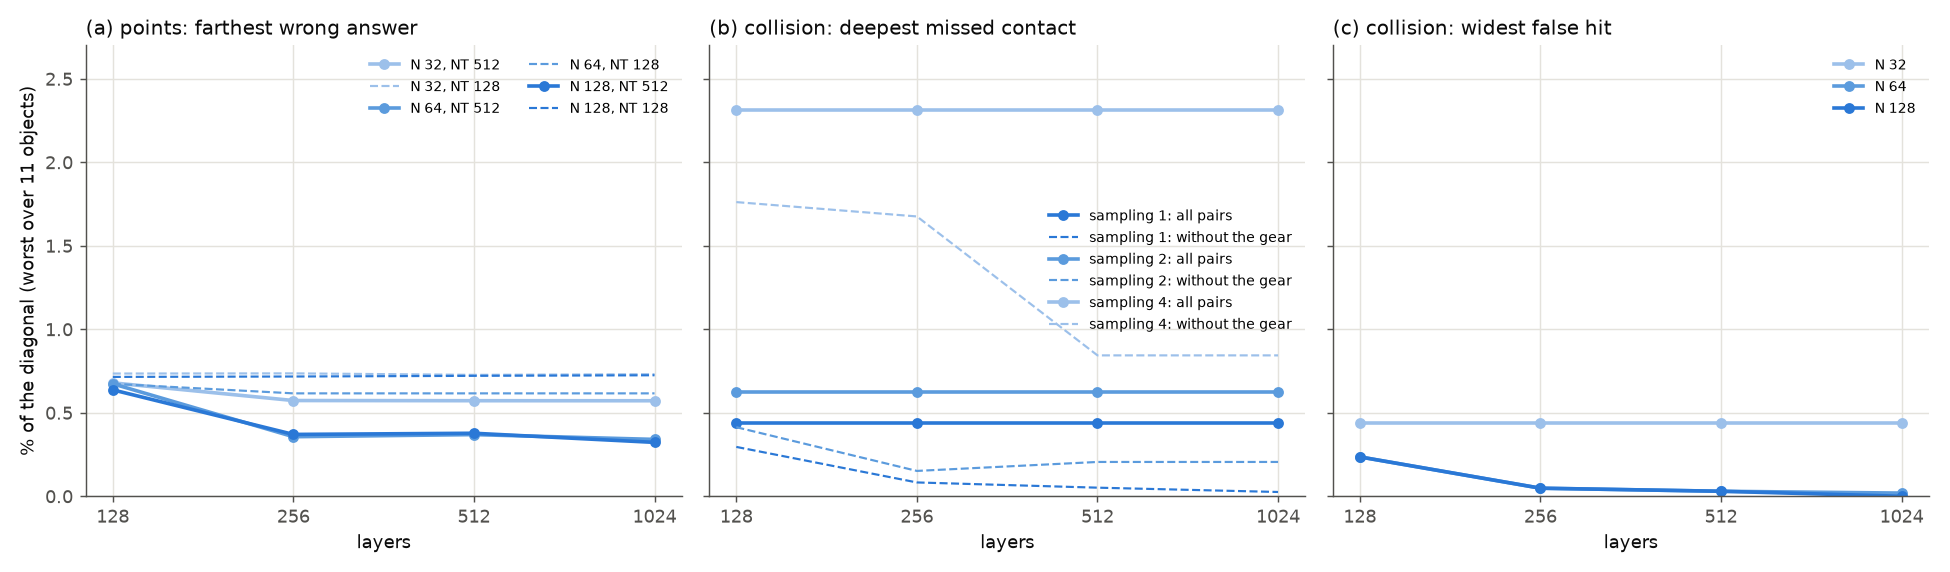
| layers | N | NT | max MB | points ε % diag | points ε w/o gear | missed contact ε sampling 1 | sampling 2 | sampling 4 | missed ε s1 w/o gear | false hit ε sampling 1 | near ns/pt (median) | µs/pose s1 (median) |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 128 | 32 | 128 | 0.16 | 0.73 | 0.68 | 0.62 | 0.63 | 2.55 | 0.30 | 0.24 | 4.7 | 3.83 |
| 128 | 32 | 256 | 0.16 | 0.68 | 0.68 | 0.62 | 0.62 | 2.55 | 0.30 | 0.44 | 6.1 | 4.32 |
| 128 | 32 | 512 | 0.16 | 0.68 | 0.68 | 0.62 | 0.62 | 2.55 | 0.30 | 0.44 | 8.0 | 5.25 |
| 128 | 64 | 128 | 0.29 | 0.67 | 0.67 | 0.62 | 1.04 | 2.31 | 0.30 | 0.24 | 4.7 | 3.81 |
| 128 | 64 | 256 | 0.29 | 0.67 | 0.67 | 0.47 | 0.62 | 2.31 | 0.30 | 0.24 | 6.1 | 4.30 |
| 128 | 64 | 512 | 0.29 | 0.67 | 0.67 | 0.47 | 0.62 | 2.31 | 0.30 | 0.24 | 8.1 | 4.77 |
| 128 | 128 | 128 | 0.49 | 0.71 | 0.64 | 0.62 | 1.04 | 2.31 | 0.30 | 0.24 | 4.7 | 3.83 |
| 128 | 128 | 256 | 0.49 | 0.64 | 0.64 | 0.44 | 1.04 | 2.31 | 0.30 | 0.24 | 6.1 | 4.31 |
| 128 | 128 | 512 | 0.49 | 0.64 | 0.64 | 0.44 | 0.62 | 2.31 | 0.30 | 0.24 | 8.6 | 4.78 |
| 256 | 32 | 128 | 0.28 | 0.74 | 0.51 | 0.62 | 0.63 | 2.55 | 0.27 | 0.06 | 4.5 | 4.17 |
| 256 | 32 | 256 | 0.28 | 0.60 | 0.50 | 0.62 | 0.63 | 2.55 | 0.27 | 0.44 | 6.0 | 4.98 |
| 256 | 32 | 512 | 0.28 | 0.57 | 0.50 | 0.62 | 0.62 | 2.55 | 0.27 | 0.44 | 9.0 | 5.20 |
| 256 | 64 | 128 | 0.51 | 0.62 | 0.36 | 0.62 | 0.62 | 2.31 | 0.08 | 0.05 | 4.5 | 4.19 |
| 256 | 64 | 256 | 0.51 | 0.36 | 0.36 | 0.47 | 0.62 | 2.31 | 0.08 | 0.05 | 6.0 | 4.99 |
| 256 | 64 | 512 | 0.51 | 0.36 | 0.36 | 0.47 | 0.62 | 2.31 | 0.08 | 0.05 | 9.1 | 5.22 |
| 256 | 128 | 128 | 0.86 | 0.72 | 0.40 | 0.62 | 1.04 | 2.31 | 0.08 | 0.05 | 4.5 | 4.17 |
| 256 | 128 | 256 | 0.86 | 0.37 | 0.37 | 0.08 | 1.04 | 2.31 | 0.08 | 0.05 | 6.1 | 4.91 |
| 256 | 128 | 512 | 0.86 | 0.37 | 0.37 | 0.44 | 0.62 | 2.31 | 0.08 | 0.05 | 9.1 | 5.21 |
| 512 | 32 | 128 | 0.48 | 0.73 | 0.46 | 0.62 | 1.04 | 2.55 | 0.27 | 0.06 | 5.0 | 5.11 |
| 512 | 32 | 256 | 0.48 | 0.60 | 0.53 | 0.62 | 0.63 | 2.55 | 0.27 | 0.44 | 6.3 | 5.17 |
| 512 | 32 | 512 | 0.48 | 0.57 | 0.53 | 0.62 | 0.63 | 2.55 | 0.27 | 0.44 | 9.7 | 5.90 |
| 512 | 64 | 128 | 0.84 | 0.62 | 0.37 | 0.62 | 0.62 | 2.31 | 0.03 | 0.03 | 4.7 | 5.11 |
| 512 | 64 | 256 | 0.84 | 0.37 | 0.37 | 0.47 | 0.62 | 2.31 | 0.03 | 0.03 | 6.3 | 5.19 |
| 512 | 64 | 512 | 0.84 | 0.37 | 0.37 | 0.47 | 0.62 | 2.31 | 0.03 | 0.03 | 10.1 | 5.93 |
| 512 | 128 | 128 | 1.38 | 0.72 | 0.38 | 0.62 | 1.04 | 2.31 | 0.05 | 0.03 | 4.7 | 5.11 |
| 512 | 128 | 256 | 1.38 | 0.38 | 0.38 | 0.44 | 0.62 | 2.31 | 0.05 | 0.03 | 6.3 | 5.19 |
| 512 | 128 | 512 | 1.38 | 0.38 | 0.38 | 0.44 | 0.62 | 2.31 | 0.05 | 0.03 | 10.1 | 5.95 |
| 1024 | 32 | 128 | 0.77 | 0.73 | 0.48 | 0.62 | 0.63 | 2.55 | 0.27 | 0.06 | 5.8 | 6.24 |
| 1024 | 32 | 256 | 0.77 | 0.60 | 0.48 | 0.62 | 0.63 | 2.55 | 0.27 | 0.44 | 6.6 | 6.30 |
| 1024 | 32 | 512 | 0.77 | 0.57 | 0.48 | 0.62 | 0.63 | 2.55 | 0.27 | 0.44 | 10.9 | 6.54 |
| 1024 | 64 | 128 | 1.33 | 0.62 | 0.34 | 0.62 | 0.62 | 2.31 | 0.03 | 0.02 | 5.2 | 6.27 |
| 1024 | 64 | 256 | 1.33 | 0.35 | 0.34 | 0.47 | 0.62 | 2.31 | 0.03 | 0.02 | 6.6 | 6.32 |
| 1024 | 64 | 512 | 1.33 | 0.34 | 0.34 | 0.47 | 0.62 | 2.31 | 0.03 | 0.02 | 10.8 | 6.58 |
| 1024 | 128 | 128 | 2.18 | 0.72 | 0.35 | 0.62 | 1.04 | 2.31 | 0.05 | 0.00 | 7.1 | 6.25 |
| 1024 | 128 | 256 | 2.18 | 0.32 | 0.32 | 0.44 | 0.62 | 2.31 | 0.05 | 0.00 | 7.9 | 6.32 |
| 1024 | 128 | 512 | 2.18 | 0.32 | 0.32 | 0.44 | 0.62 | 2.31 | 0.03 | 0.00 | 10.7 | 6.62 |
Sampling s: collision samples every s/128 of the height and every s·NT/128-th ring vertex. Raw: bound_points.csv, bound_collide.csv (per object / pair); scripts/bound.py.
| set | FCP query | unit | time 1024 layers | time 512 layers | wrong % / accuracy % 1024 layers | wrong % / accuracy % 512 layers |
|---|---|---|---|---|---|---|
| everyday | points near, (CUDA) | ns/pt | 9.36 | 9.54 | 0.291 | 0.497 |
| everyday | points near, (CPU) | ns/pt | 26.75 | 75.88 | 0.291 | 0.497 |
| everyday | points uniform, (CUDA) | ns/pt | 3.30 | 3.29 | 0.039 | 0.064 |
| everyday | points uniform, (CPU) | ns/pt | 21.05 | 40.26 | 0.039 | 0.064 |
| everyday | collision, sampling 1x1 (CPU) | µs/pose | 33.07 | 75.68 | 99.960 | 99.950 |
| everyday | collision, sampling 1x1 (CUDA) | µs/pose | 6.93 | 5.97 | 99.960 | 99.950 |
| everyday | collision, sampling 2x2 (CPU) | µs/pose | 10.05 | 24.45 | 99.890 | 99.900 |
| everyday | collision, sampling 2x2 (CUDA) | µs/pose | 2.89 | 2.92 | 99.890 | 99.900 |
| everyday | collision, sampling 4x4 (CPU) | µs/pose | 3.84 | 9.58 | 99.710 | 99.730 |
| everyday | collision, sampling 4x4 (CUDA) | µs/pose | 1.82 | 1.64 | 99.710 | 99.730 |
| complex | points near, (CUDA) | ns/pt | 9.84 | 9.43 | 0.348 | 0.499 |
| complex | points near, (CPU) | ns/pt | 27.32 | 75.12 | 0.348 | 0.499 |
| complex | points uniform, (CUDA) | ns/pt | 4.91 | 6.01 | 0.080 | 0.116 |
| complex | points uniform, (CPU) | ns/pt | 21.40 | 53.53 | 0.080 | 0.116 |
| complex | collision, sampling 1x1 (CPU) | µs/pose | 25.18 | 47.55 | 99.908 | 99.892 |
| complex | collision, sampling 1x1 (CUDA) | µs/pose | 7.14 | 6.69 | 99.908 | 99.892 |
| complex | collision, sampling 2x2 (CPU) | µs/pose | 7.35 | 17.91 | 99.800 | 99.750 |
| complex | collision, sampling 2x2 (CUDA) | µs/pose | 3.51 | 3.54 | 99.800 | 99.750 |
| complex | collision, sampling 4x4 (CPU) | µs/pose | 2.32 | 7.75 | 99.542 | 99.567 |
| complex | collision, sampling 4x4 (CUDA) | µs/pose | 2.31 | 2.26 | 99.542 | 99.567 |
Points: wrong % of 1M points against the mesh (all distances); collision: agreement with the exact mesh test. Raw: points*_L512.csv, collide*_L512.csv.
fcp_devel/docs/HANDOVER_height_fit.md (exact end heights, a fit against the continuous
surface).slices/3d_cmp_dog.png.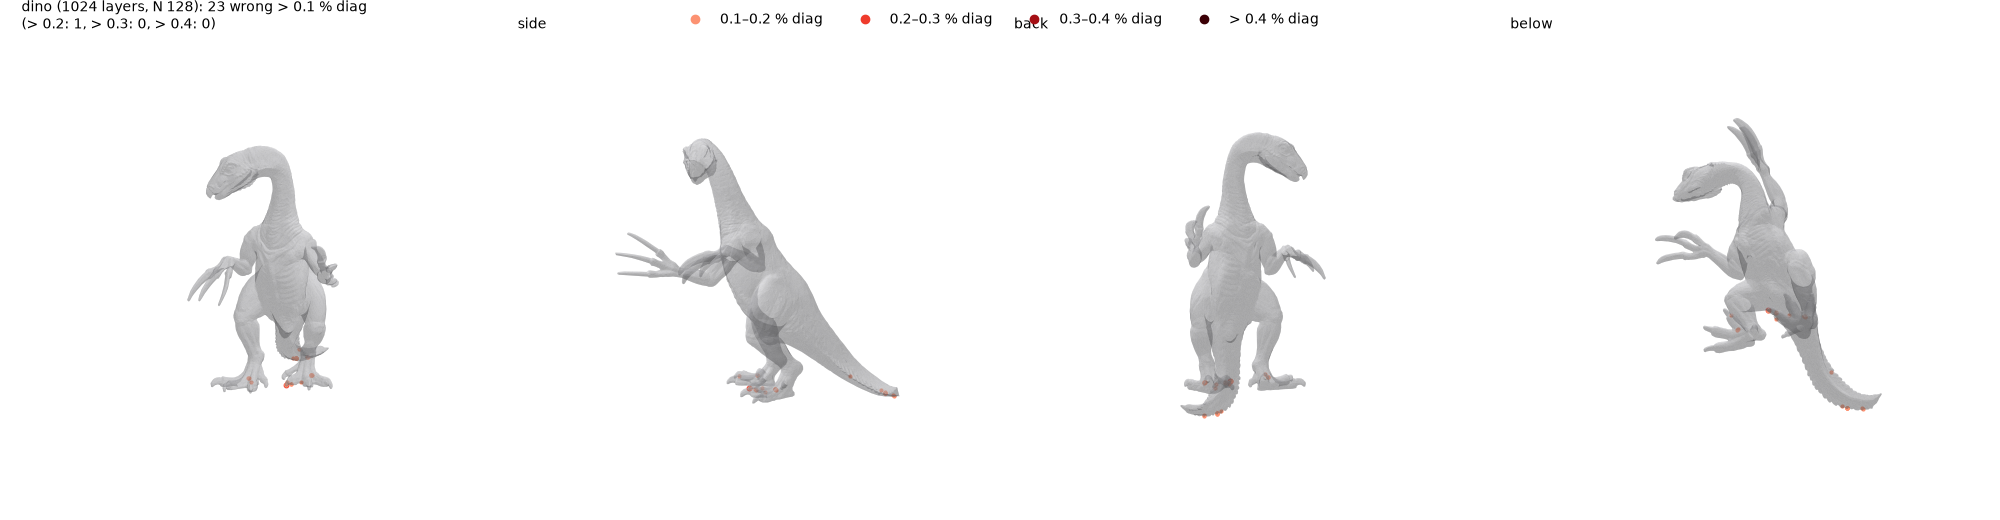
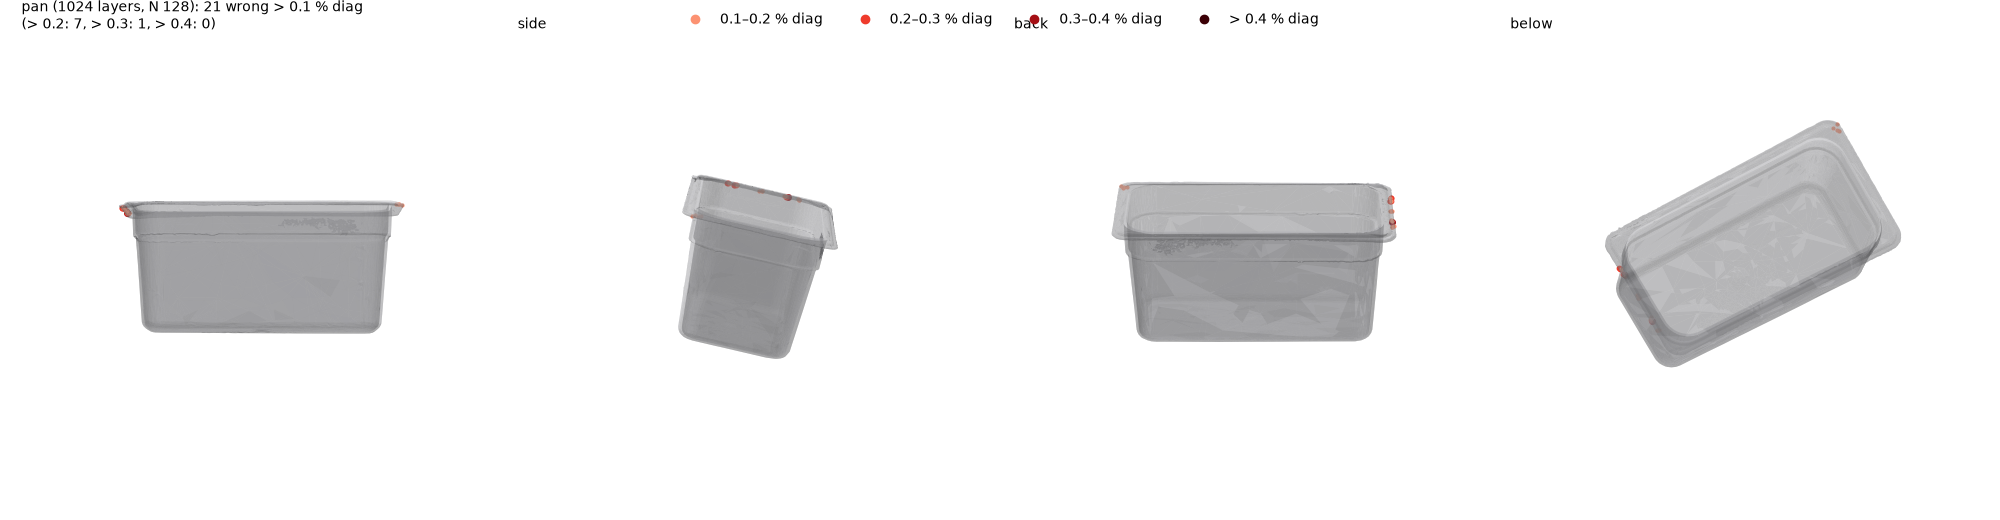
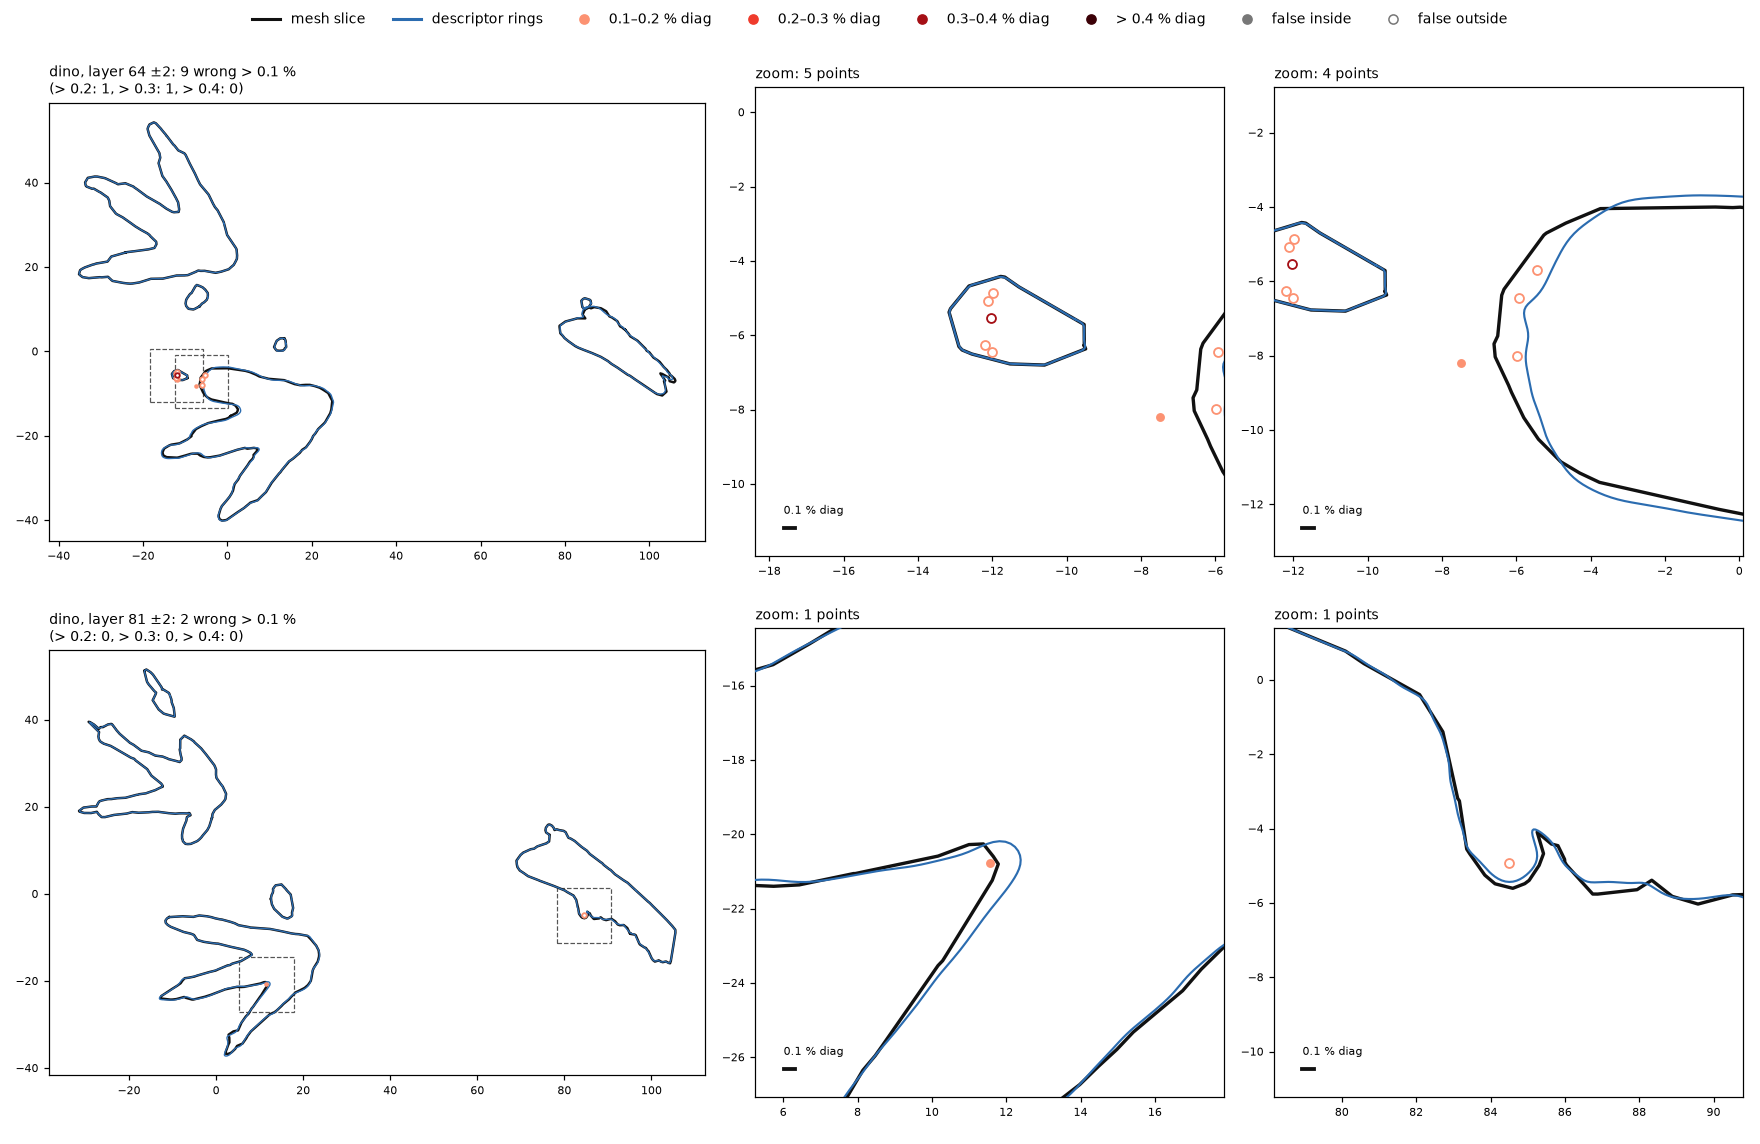
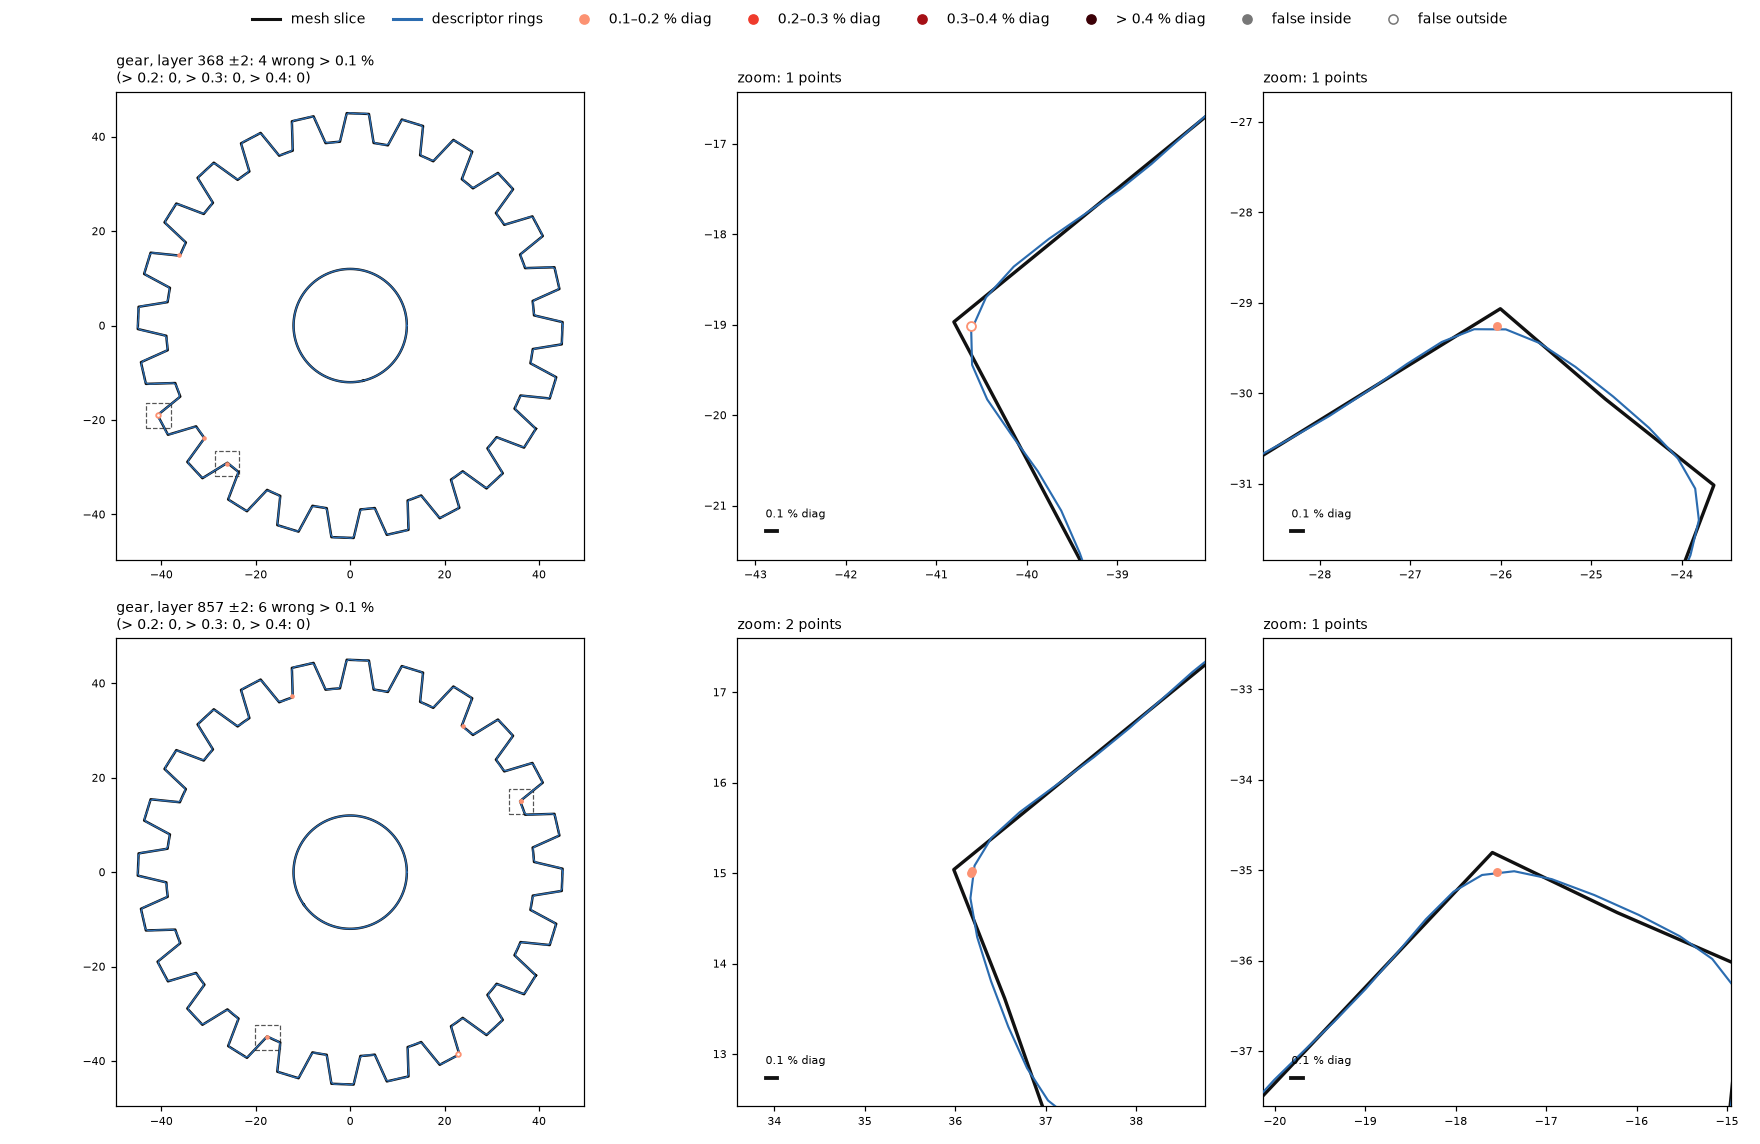
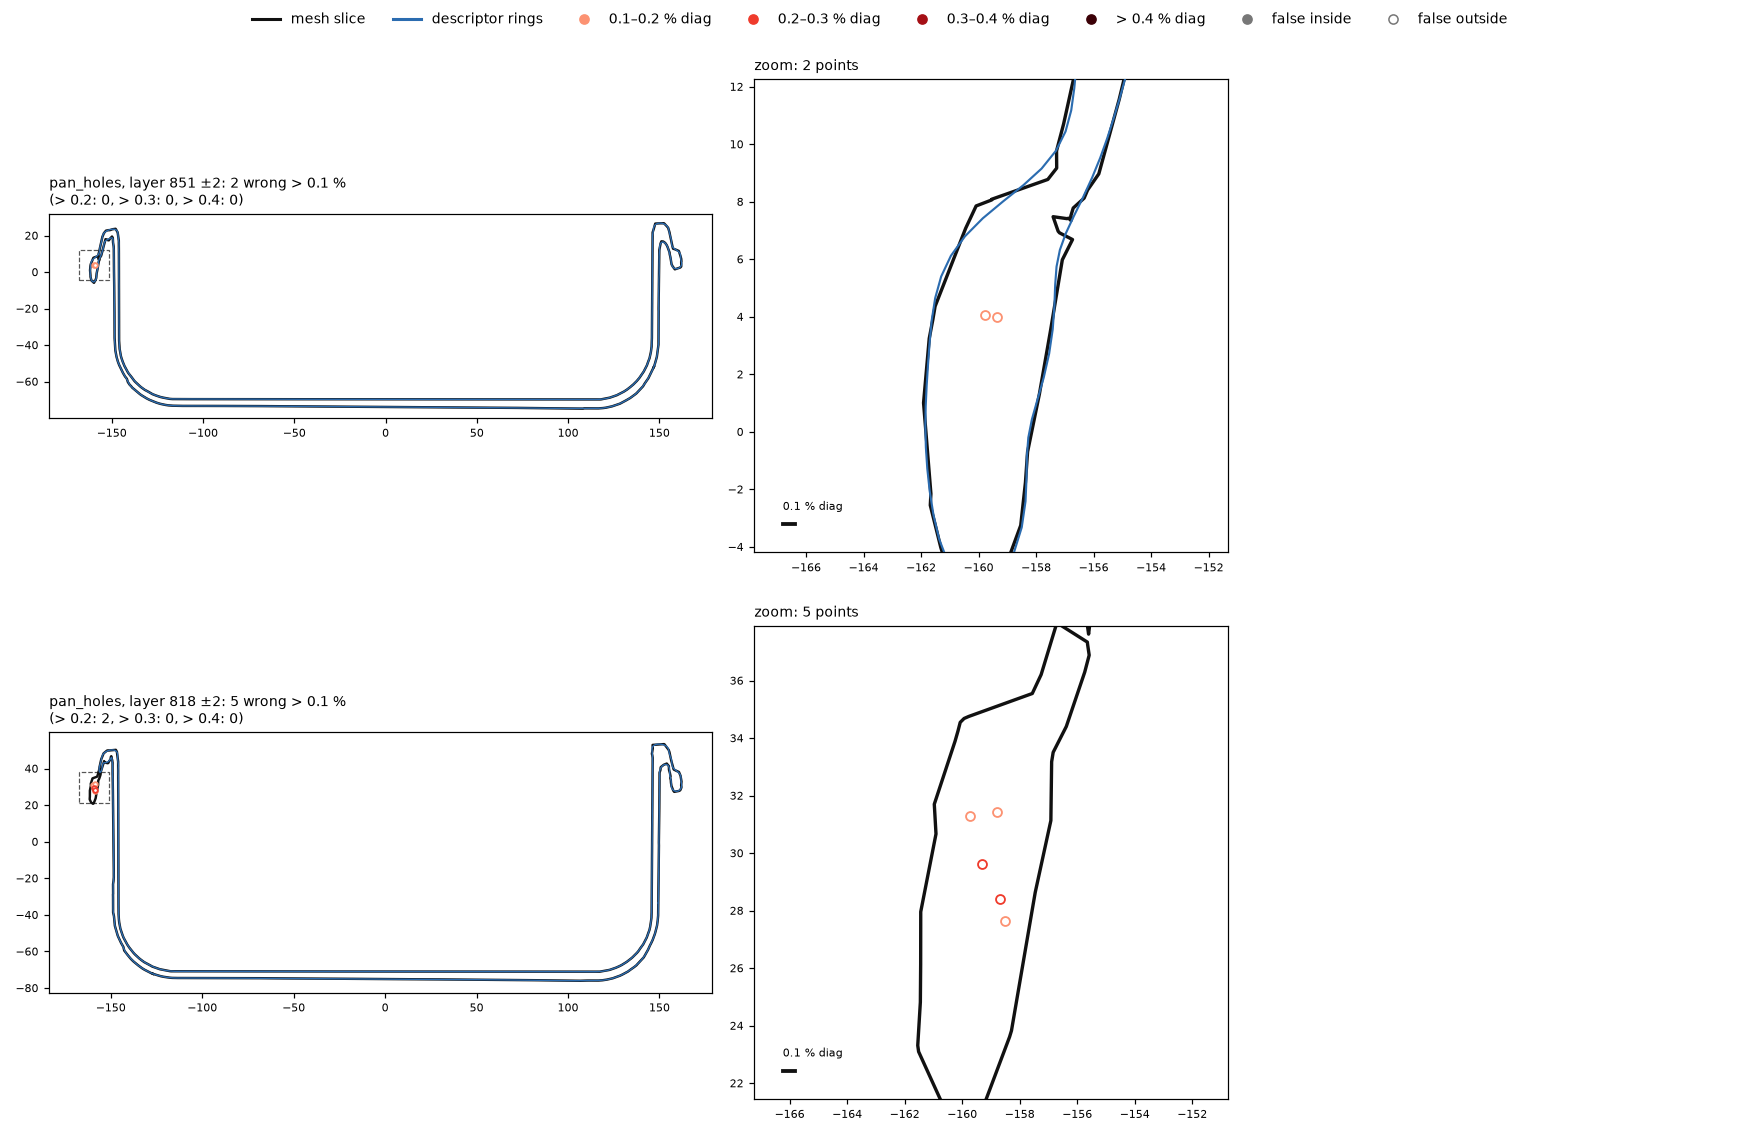

_parts.split_by_fit, v5.31): the cut at the largest
coefficient step was picked first and then had to pass the 10 % gain test; when it failed, no other cut was tried. The dog
at 2048 layers kept a 719-layer part with rings 2.6 % of the diagonal off (17 642 points wrong beyond 0.1 %, 1 699 with
the fix). Fixed in v5.4 (decision 29), which this report uses.lowmem.py).MIN_AREA_FRAC = 0.002 of the largest slice): toes, thin strips, small
holes; a fixed error no budget can remove. Every island is kept here.N_SAMPLES) caps the in-plane detail whatever N is; 2048 here.Scripts in ../scripts: fcpq.py (the descriptor queries), sweep.py and rule_cmp.py (section 1), bound.py (section 4), points_bench.py and collide_bench.py (FCP_SET=complex for section 3), slice_errors.py and render3d.py (section 5), lowmem.py (the encoder's selection without its padded array), common.py (the setting), make_shapes.py, renders.py, report.py. Raw numbers: sweep.csv, rule_cmp.csv, points*.csv, collide*.csv; logs alongside. Earlier: v1/, a6144/, a2048/.